LingYu TA2 Robot
High-performance dual-arm robot for multi-scenario remote operations
LingYu TA2 builds a remote operation loop around vision, control and feedback, enabling operators to remotely control robots at another site over public networks that meet the required connectivity conditions. Binocular vision and low-latency video transmission assist distance judgment and motion control; dual-arm coordination supports grasping, handling, contact-based interaction and multi-step tasks; and the omnidirectional mobile chassis lets the robot move freely through narrow spaces and complex paths. The platform supports continuous iterative upgrades of compute, software and features, progressively extending the robot's operating capability across different scenarios.
Configuration Matrix
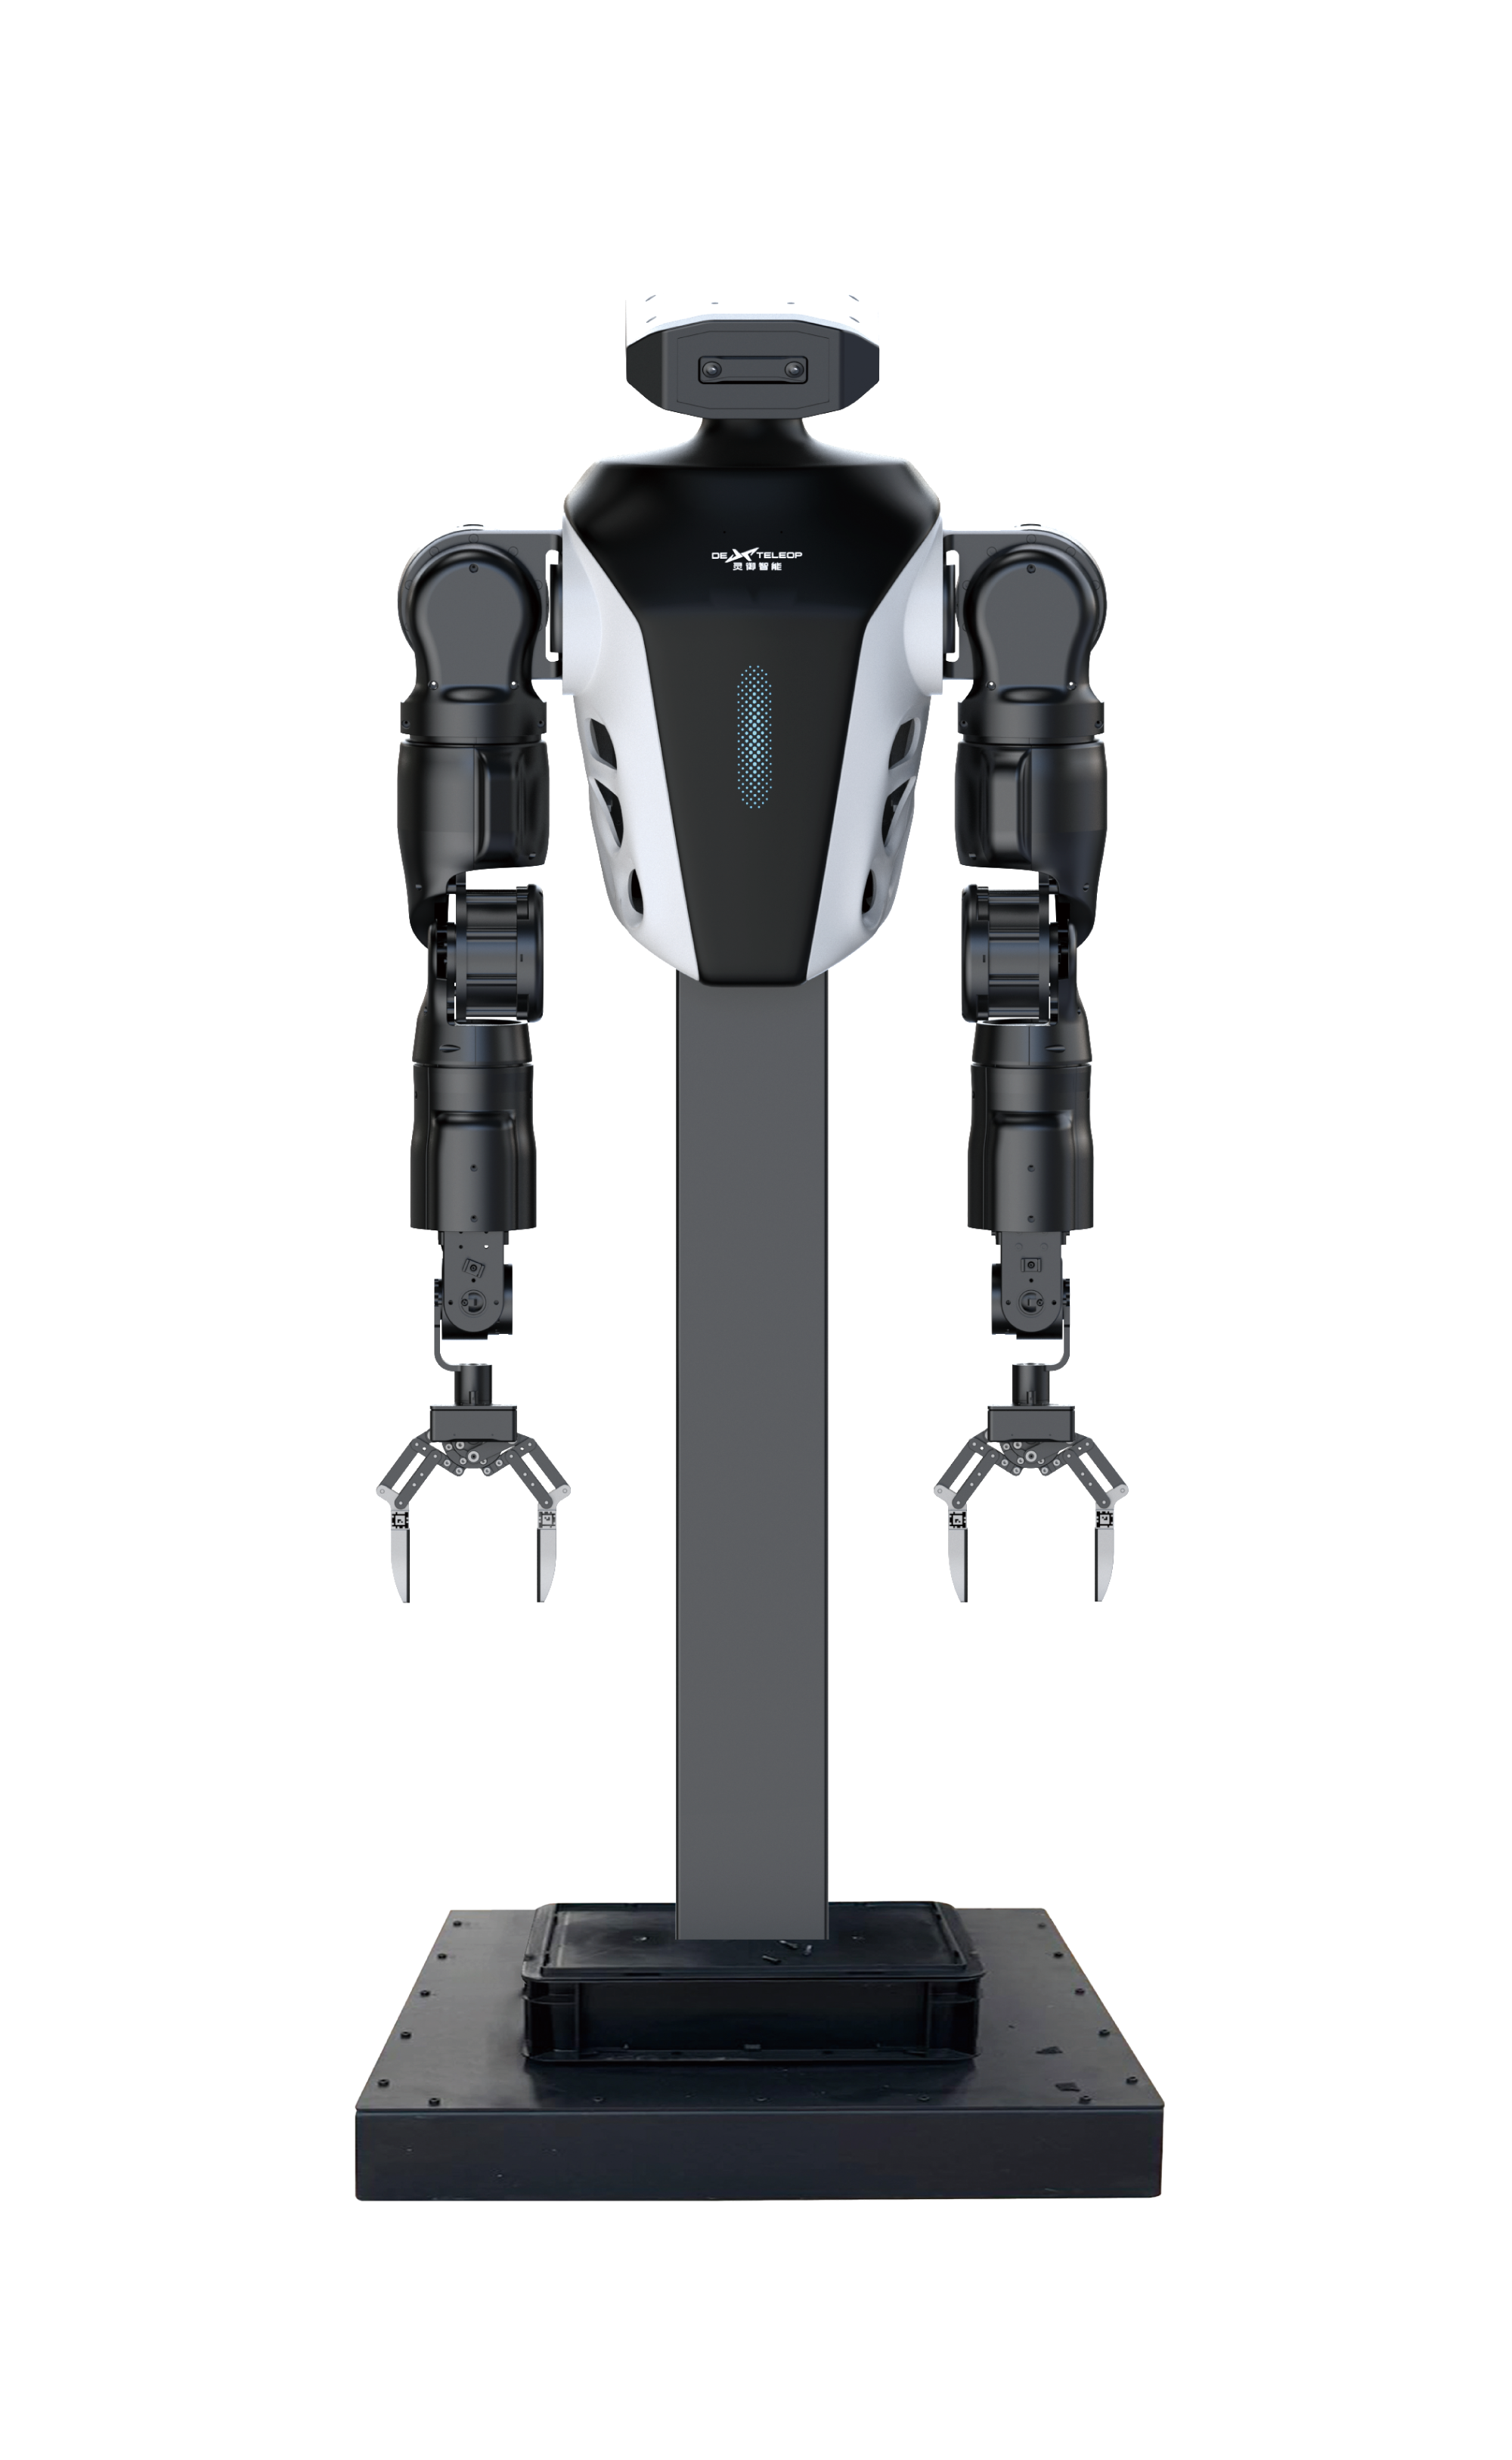
TA2 Lite
Fixed Base
Basic Training / Standardized Data Collection / Task Validation
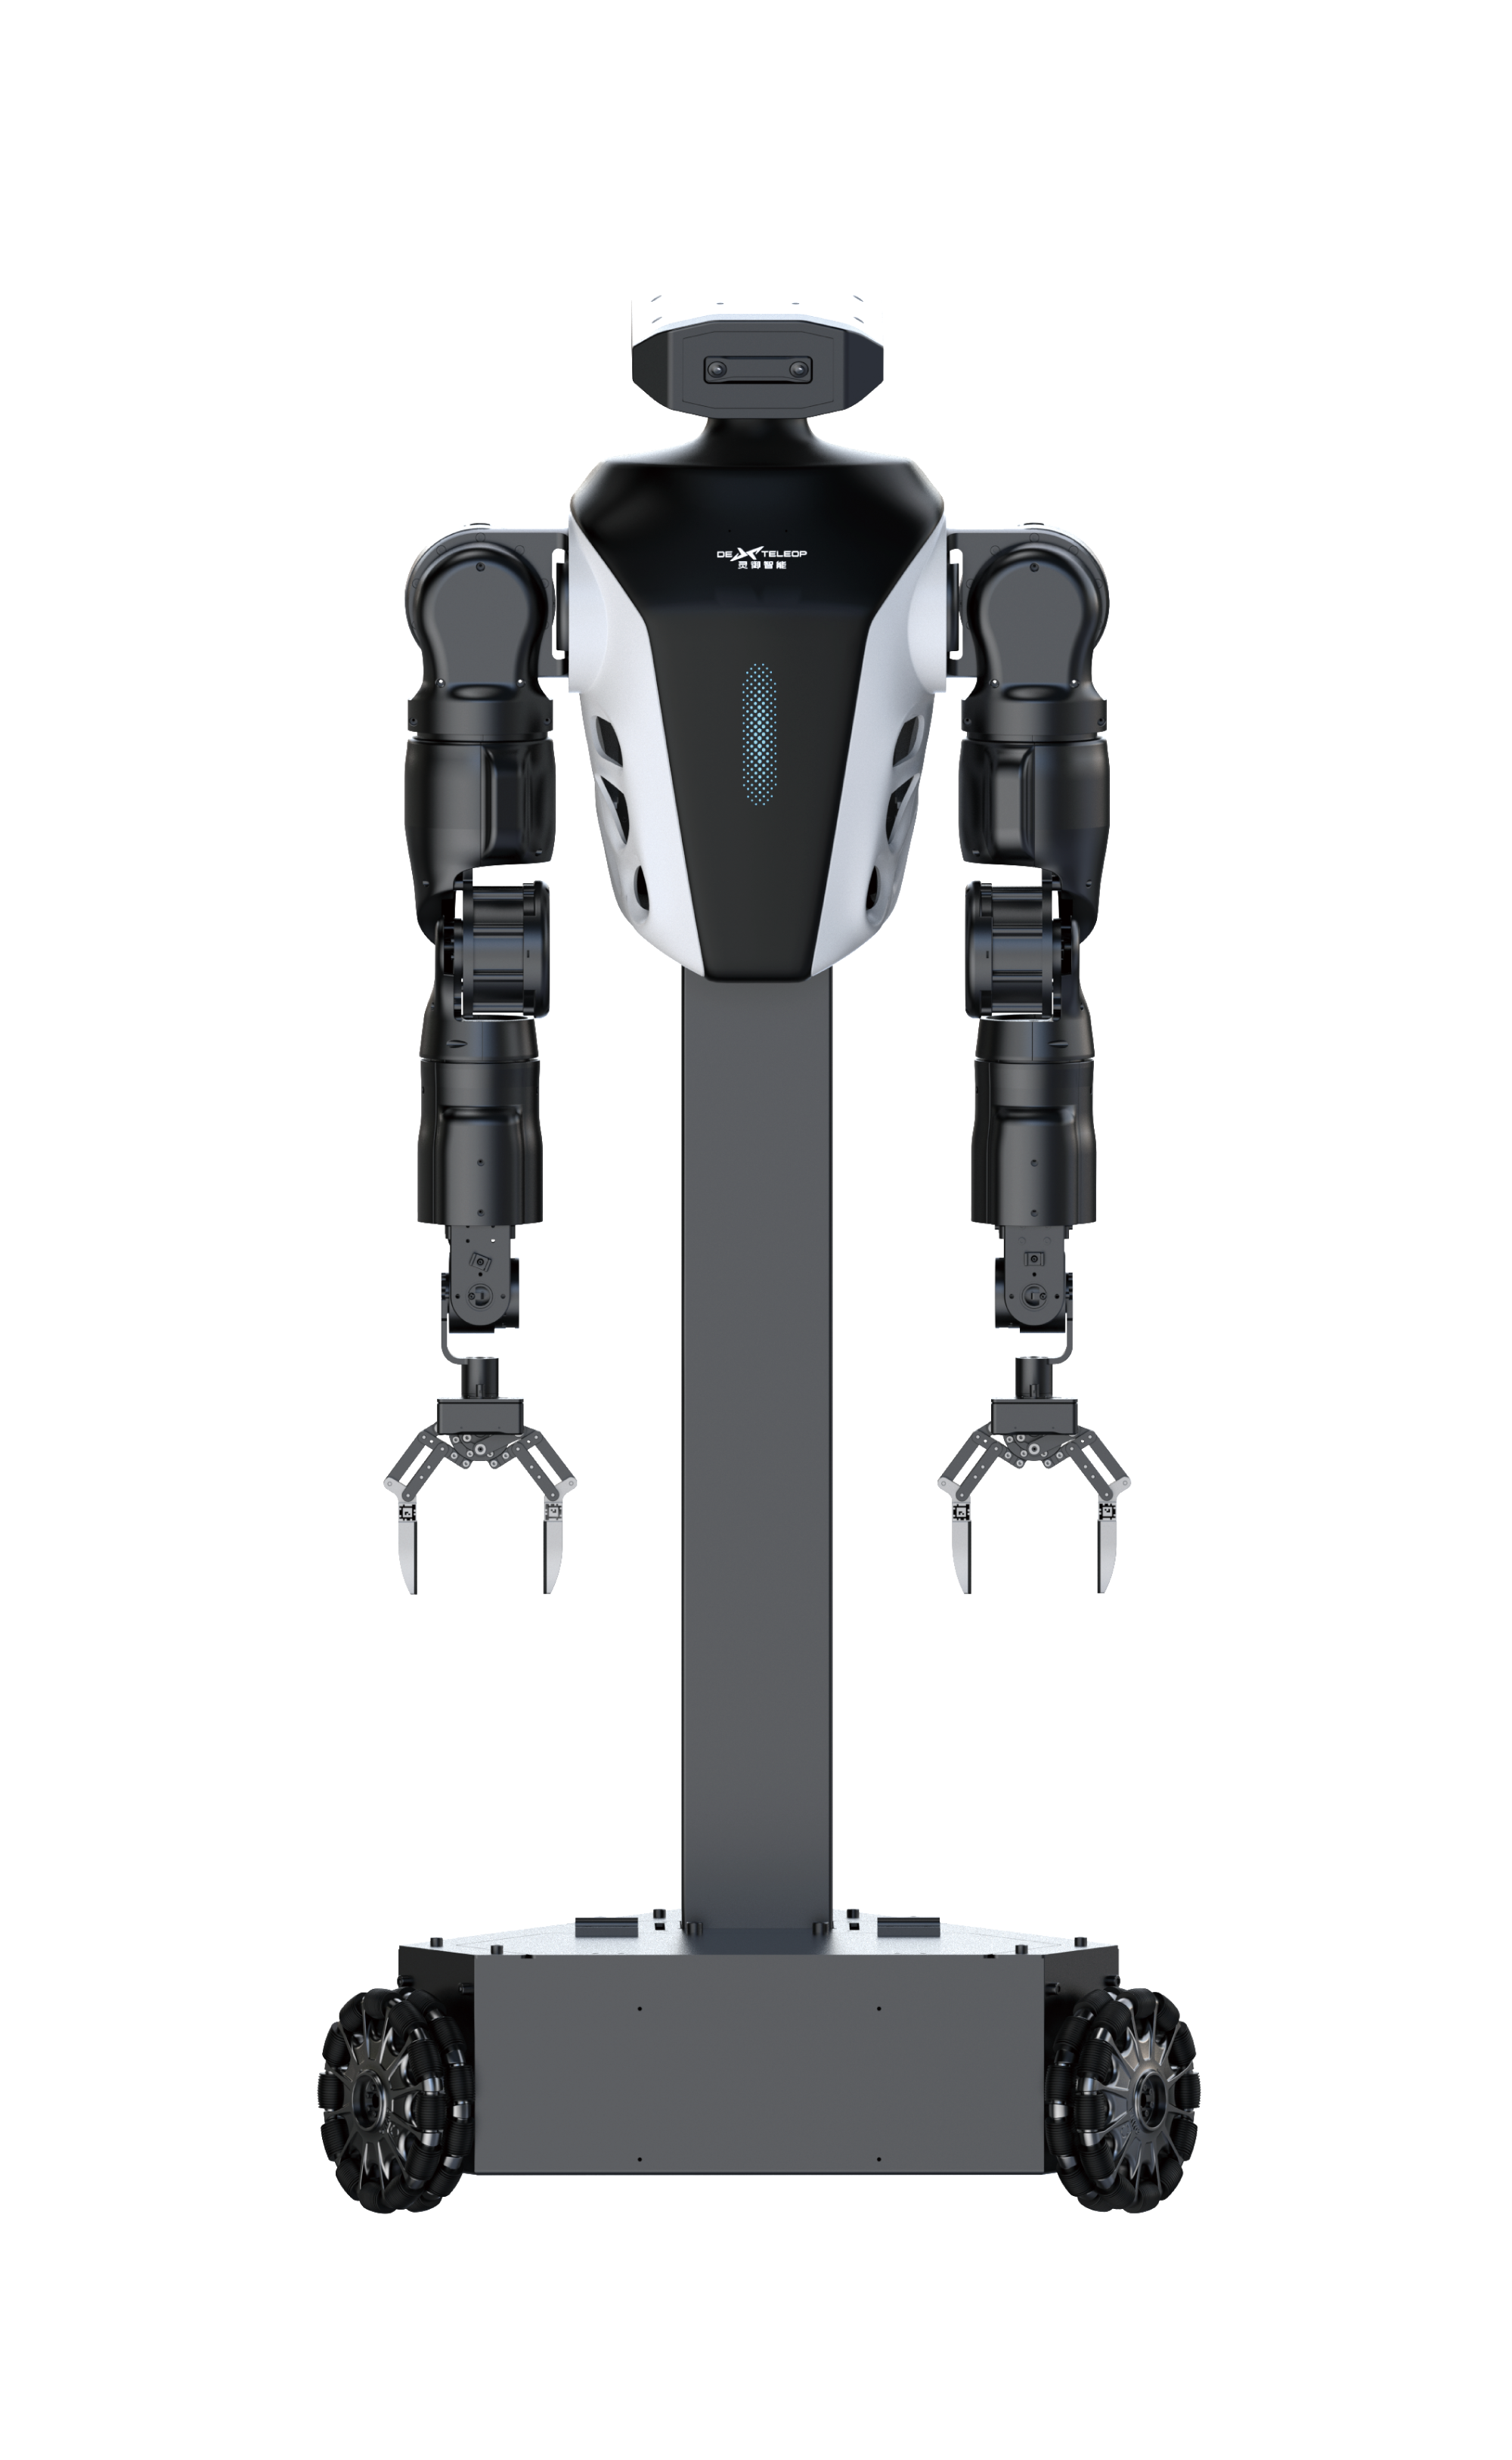
TA2 Standard
Omnidirectional Mobile Chassis
Remote Deployment / Scenario Pilot / General Validation
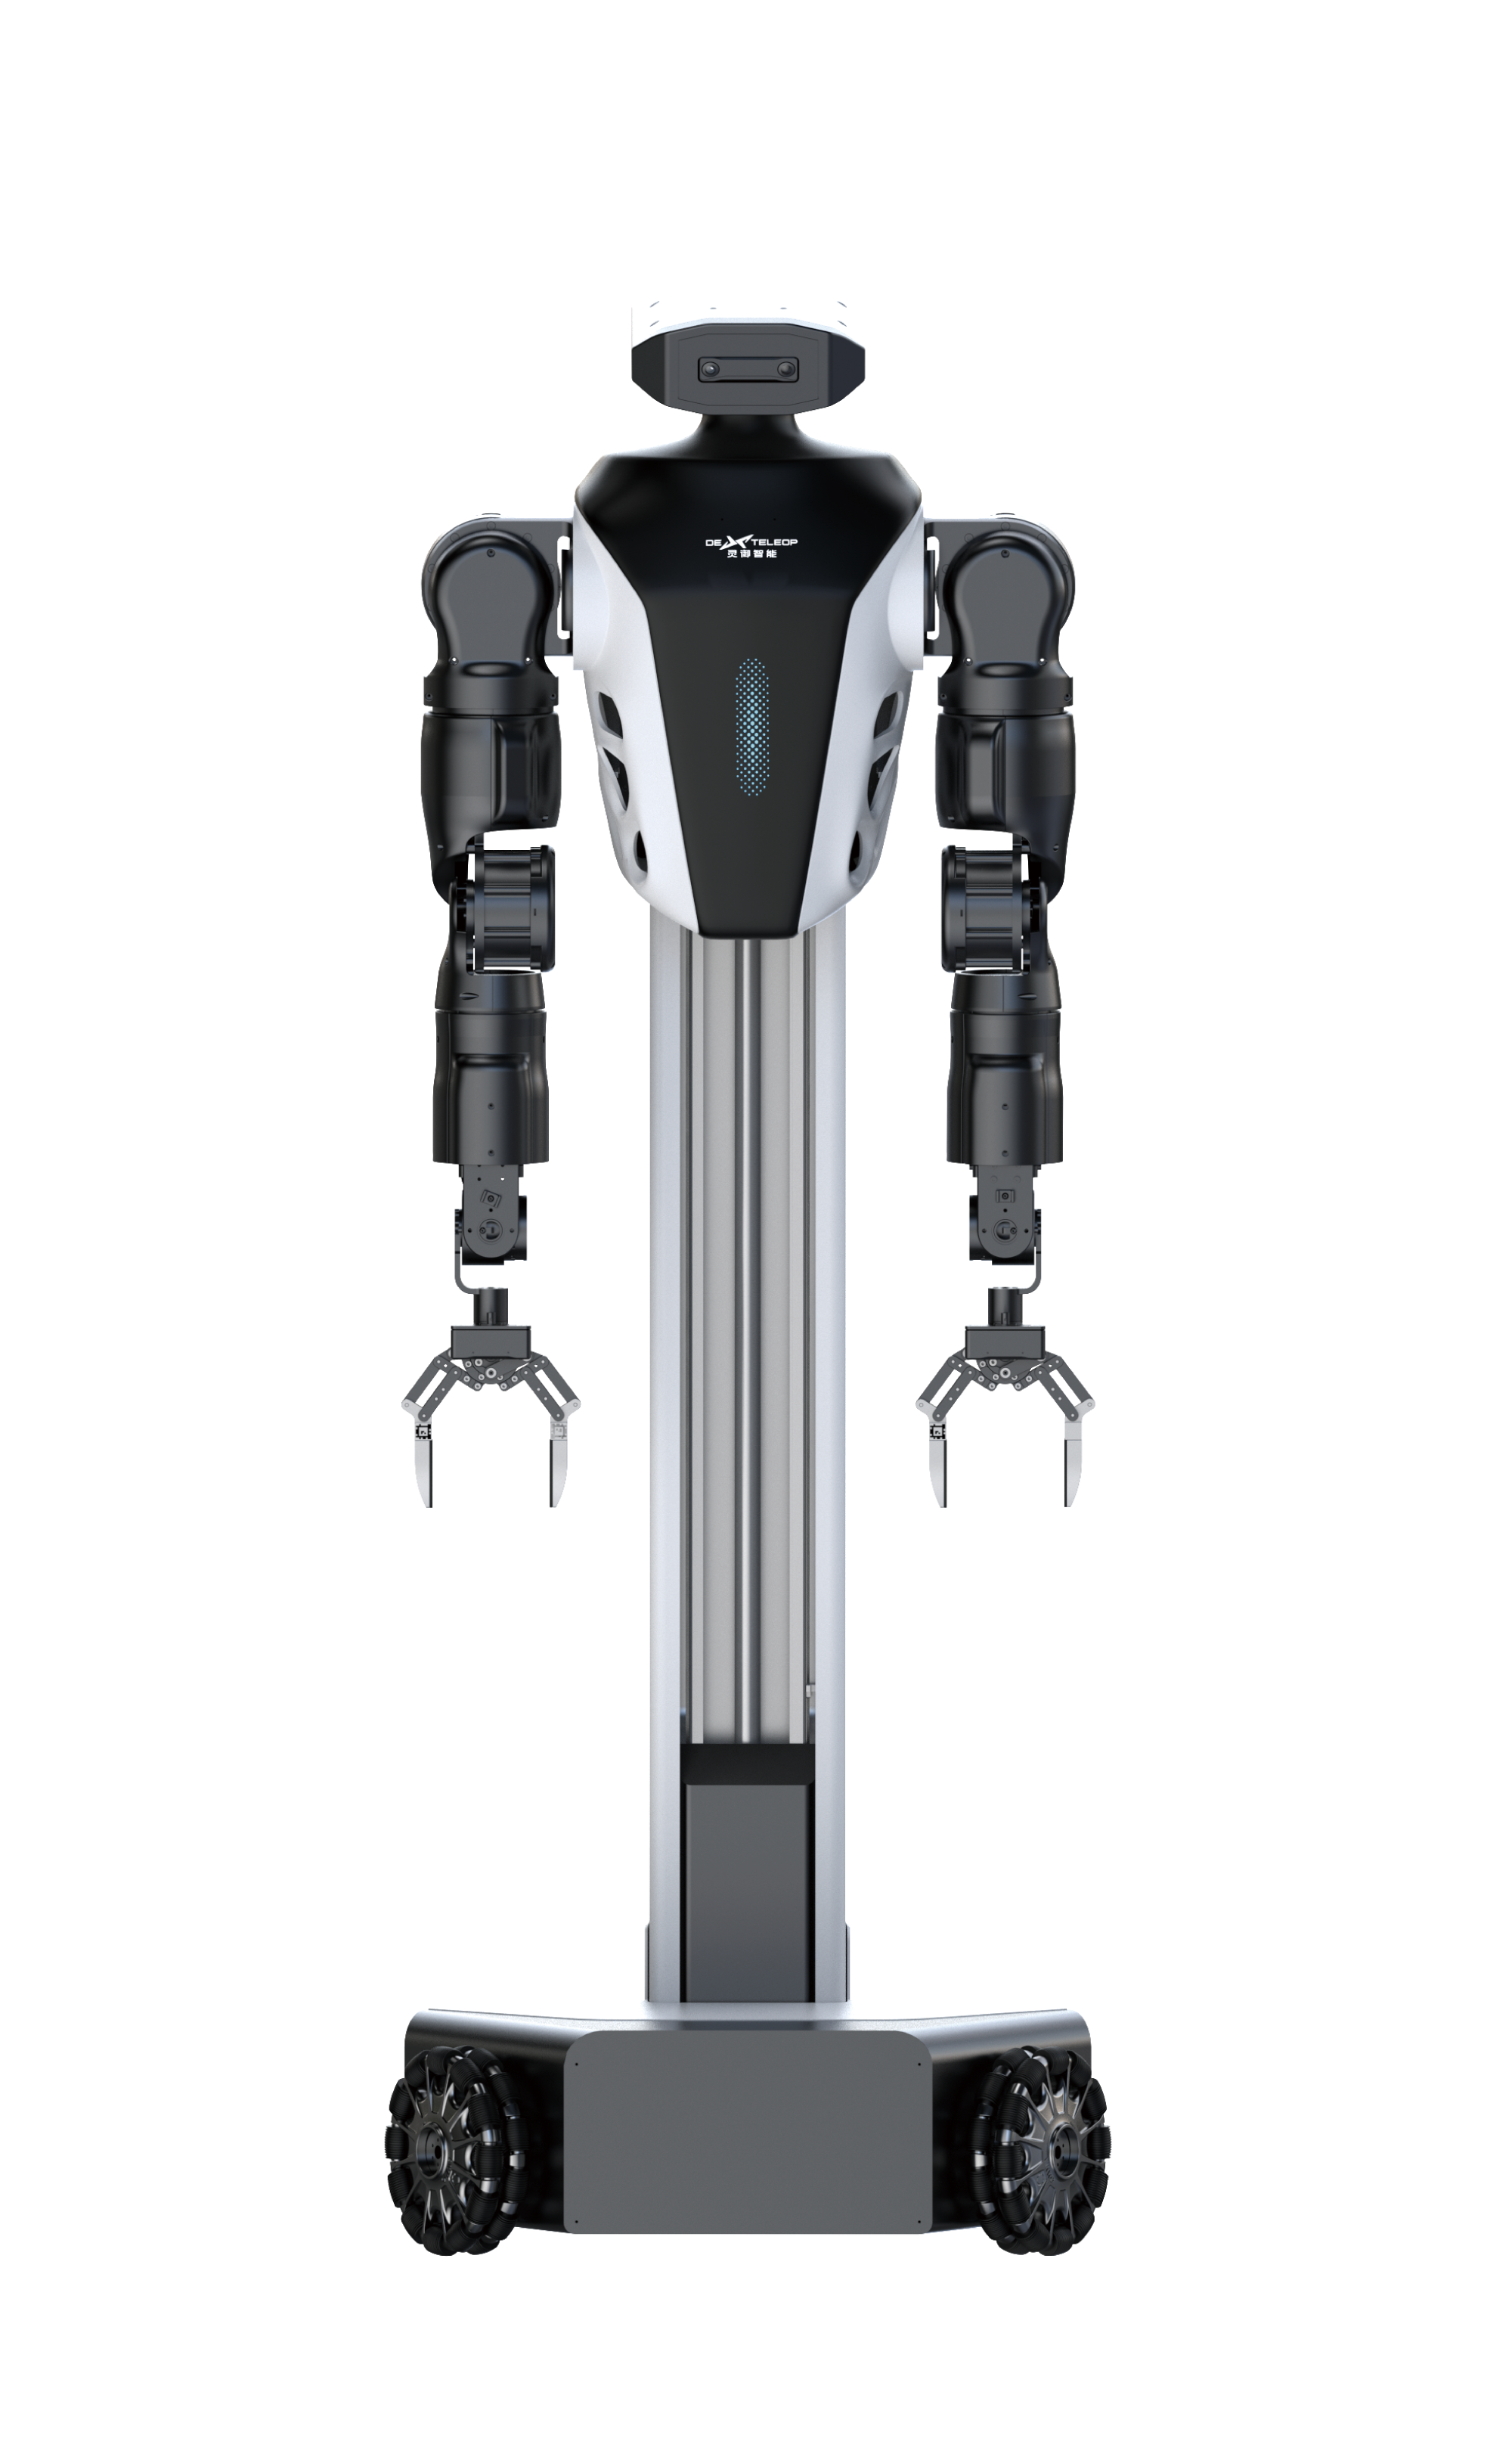
TA2 Pro
Omnidirectional Mobile + Lifting Column
Wide-area Operations / Complex Tasks / Mobile Manipulation
TA2.1 Navigation Edition
Autonomous Mobility / Auto-charging / Fleet Coordination
Self-developed Core Platform
Binocular Vision Platform
Frame sync deviation < 100 μs, video transmission latency < 90 ms
Self-developed Motion Control Platform
100% closed-form kinematics solution rate, motion control response < 30 ms
Upgradable Computing Platform
Supports multiple compute tiers, configurable to the scale of the deployed model
Omnidirectional Wheel Chassis
Agile straight-line travel combined with flexible in-place rotation, moving freely through narrow aisles with decoupled control of translation and steering, providing a stable and efficient mobile base for the upper body.
Technical Specifications
Detailed Parameter Comparison
| Parameter | Lite | Standard | Pro |
|---|---|---|---|
| Dual Arm DOF | 7-axis ×2 | 7-axis ×2 | 7-axis ×2 |
| End-effector Payload | 5kg | 5kg | 5kg |
| Omnidirectional Chassis | Not supported | Supported | Supported |
| Lifting Mechanism | None | None | Yes (700 - 1400 mm) |
| Binocular Vision | Supported | Supported | Supported |
| Video Transmission Latency | < 90 ms | < 90 ms | < 90 ms |
| Motion Control Response | < 30 ms | < 30 ms | < 30 ms |
| Battery Life | - | - | > 2h |
| Secondary Development | Supported | Supported | Supported |
Real Operating Environments
Application Scenarios
01/04
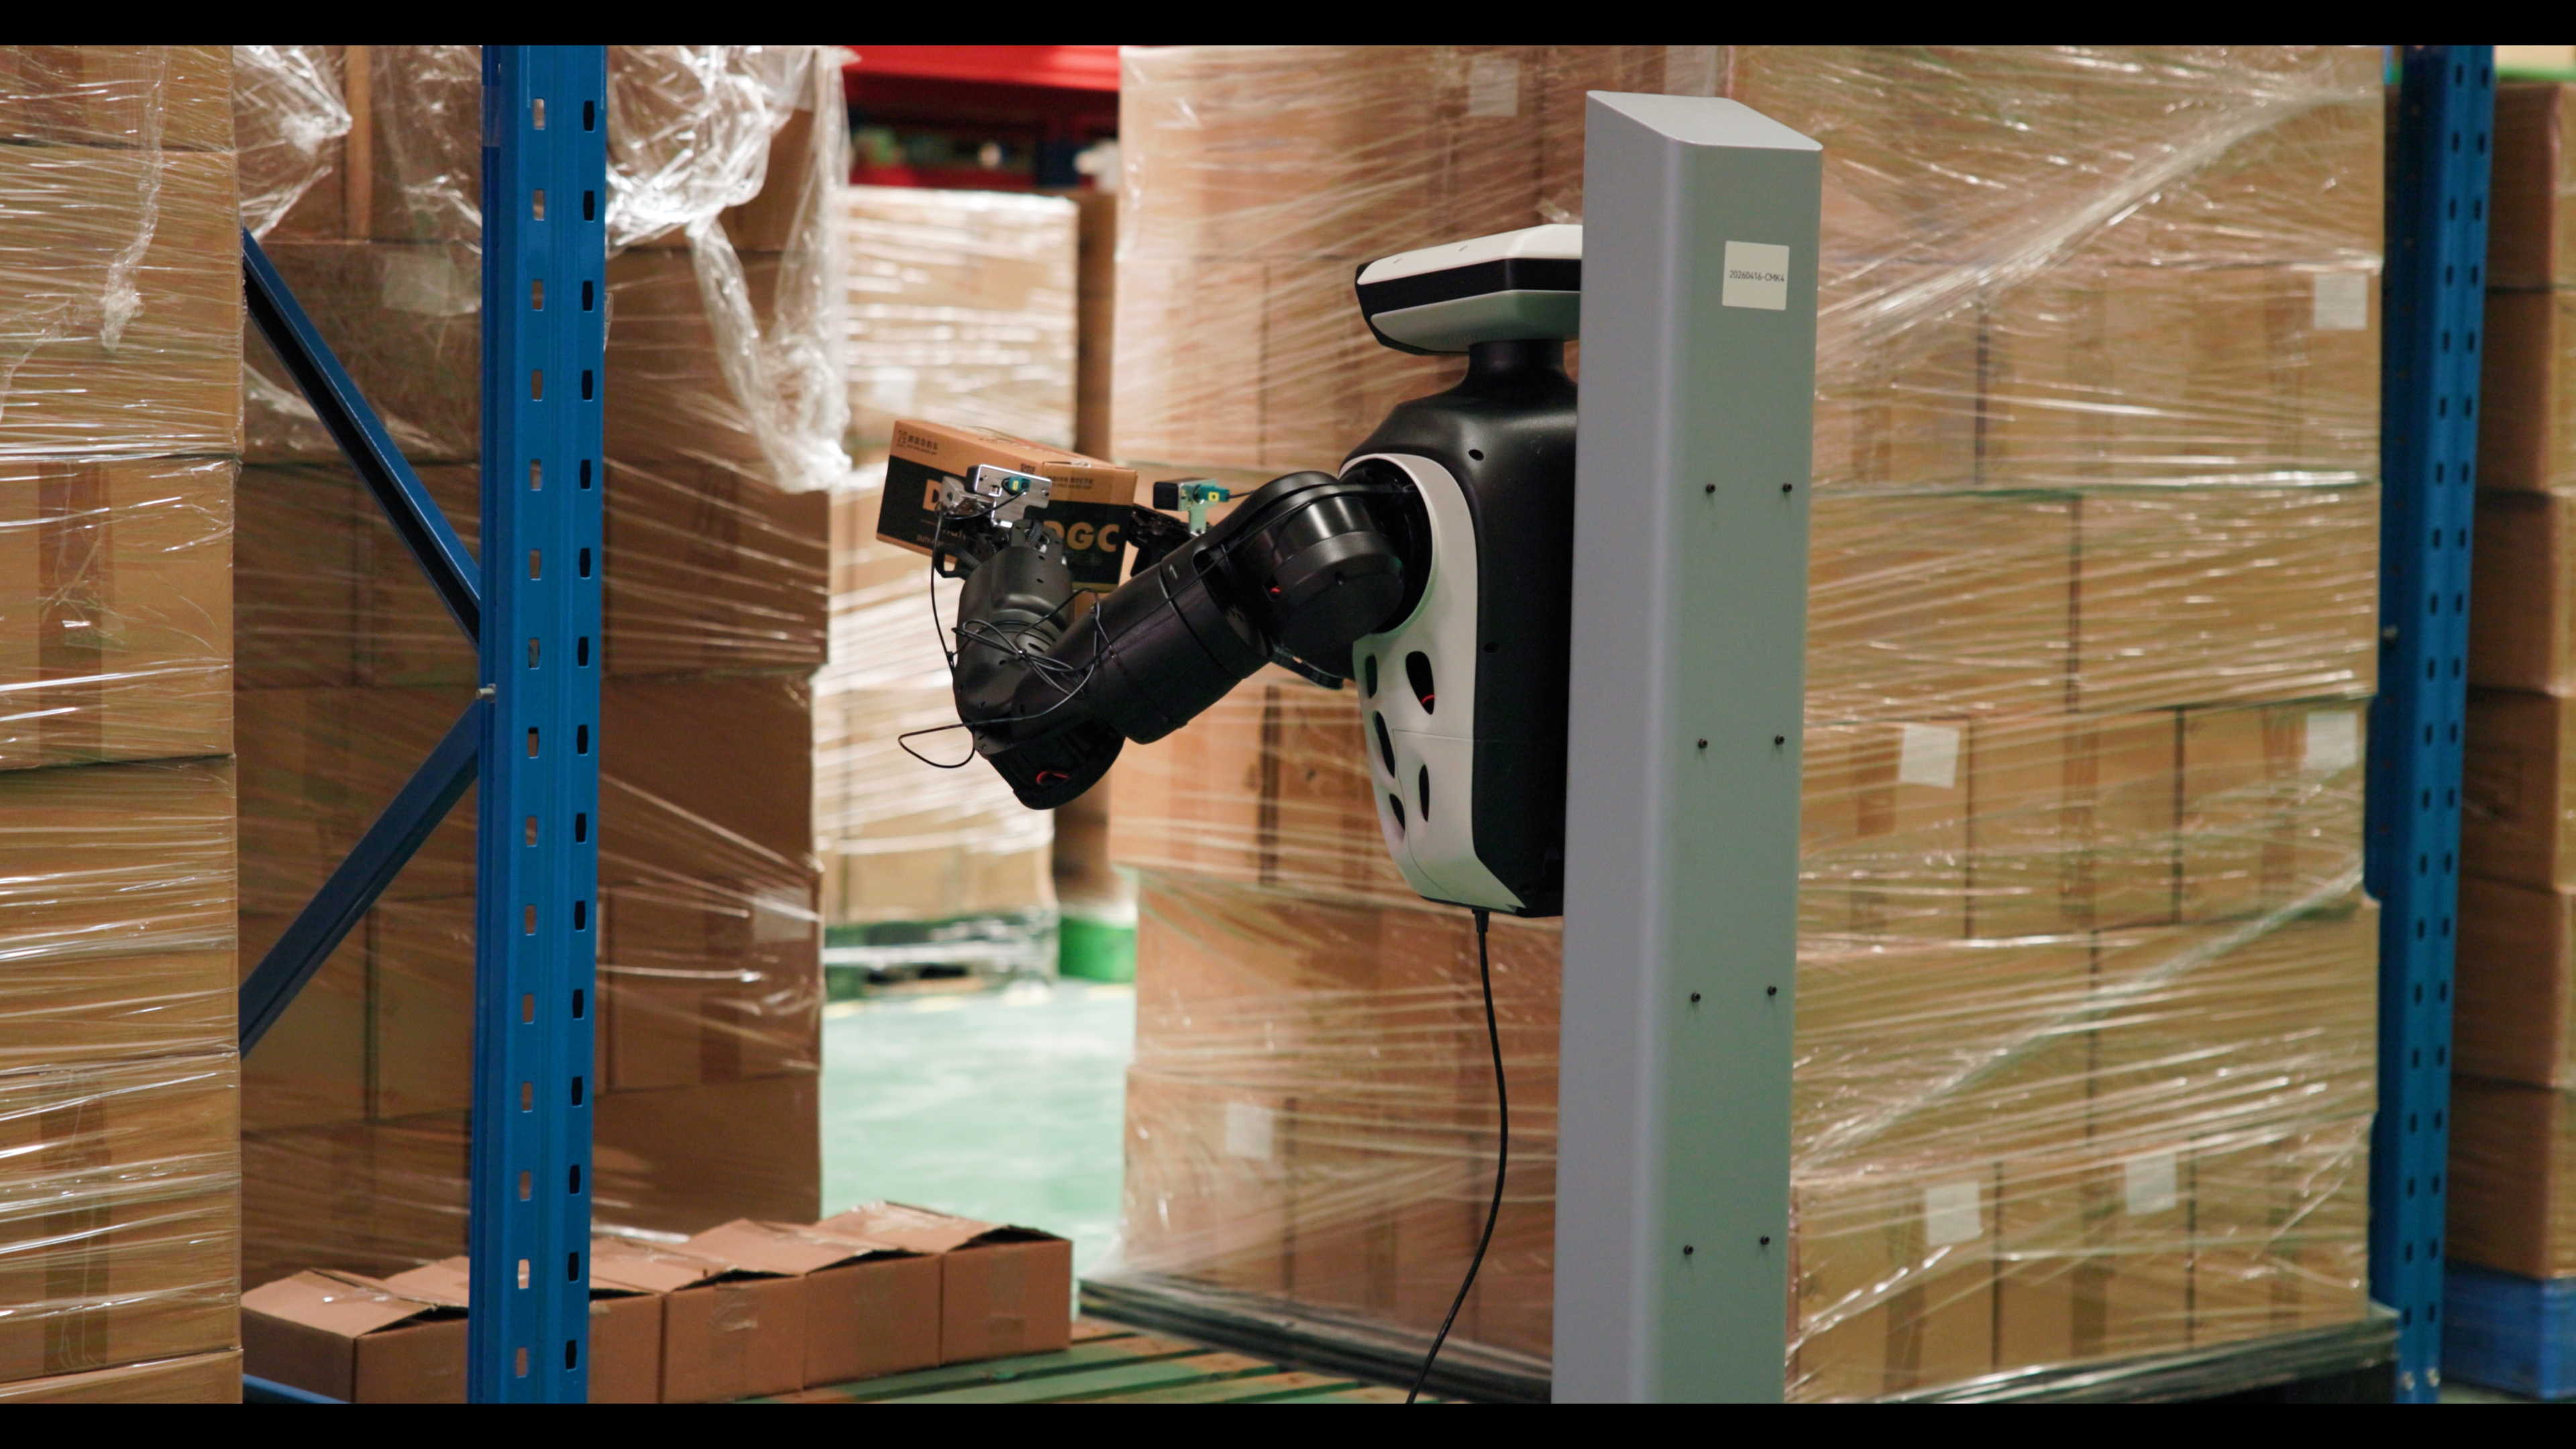
Logistics & Industrial
Non-standard item sorting, irregular package loading/unloading, handling in complex environments
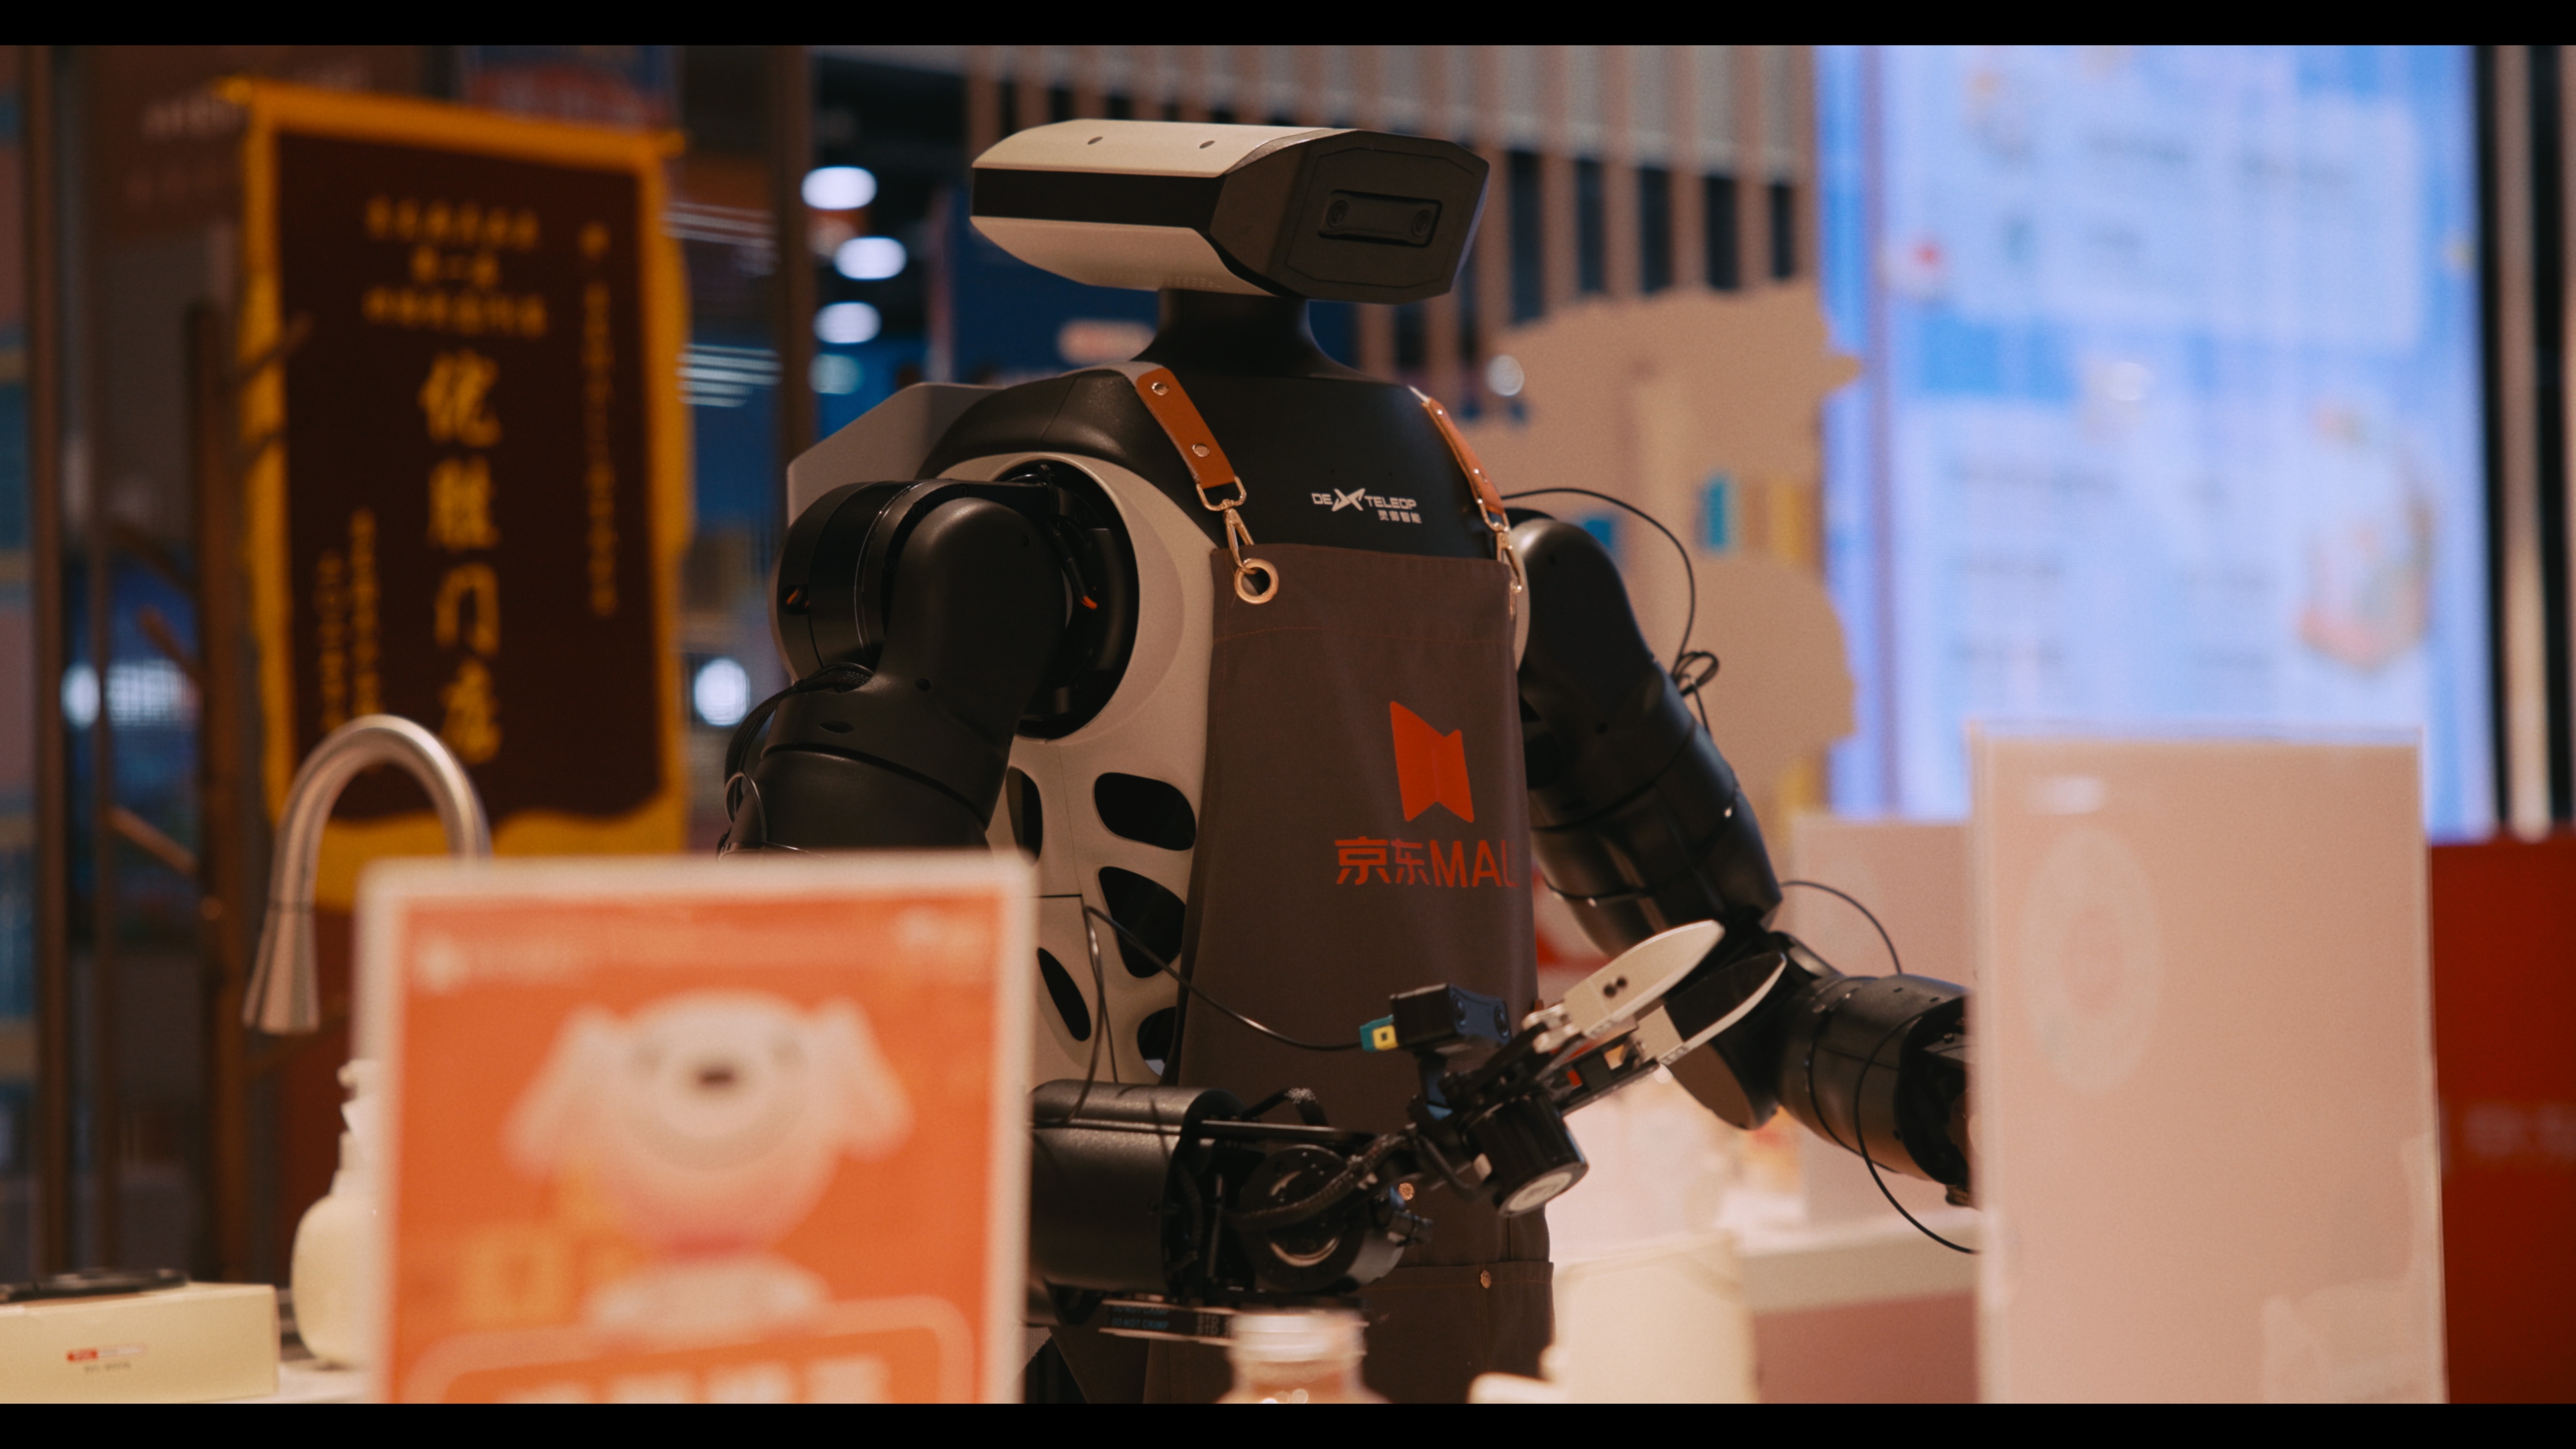
Hotel & Retail
Room tidying, unmanned convenience store stocking, overnight service support
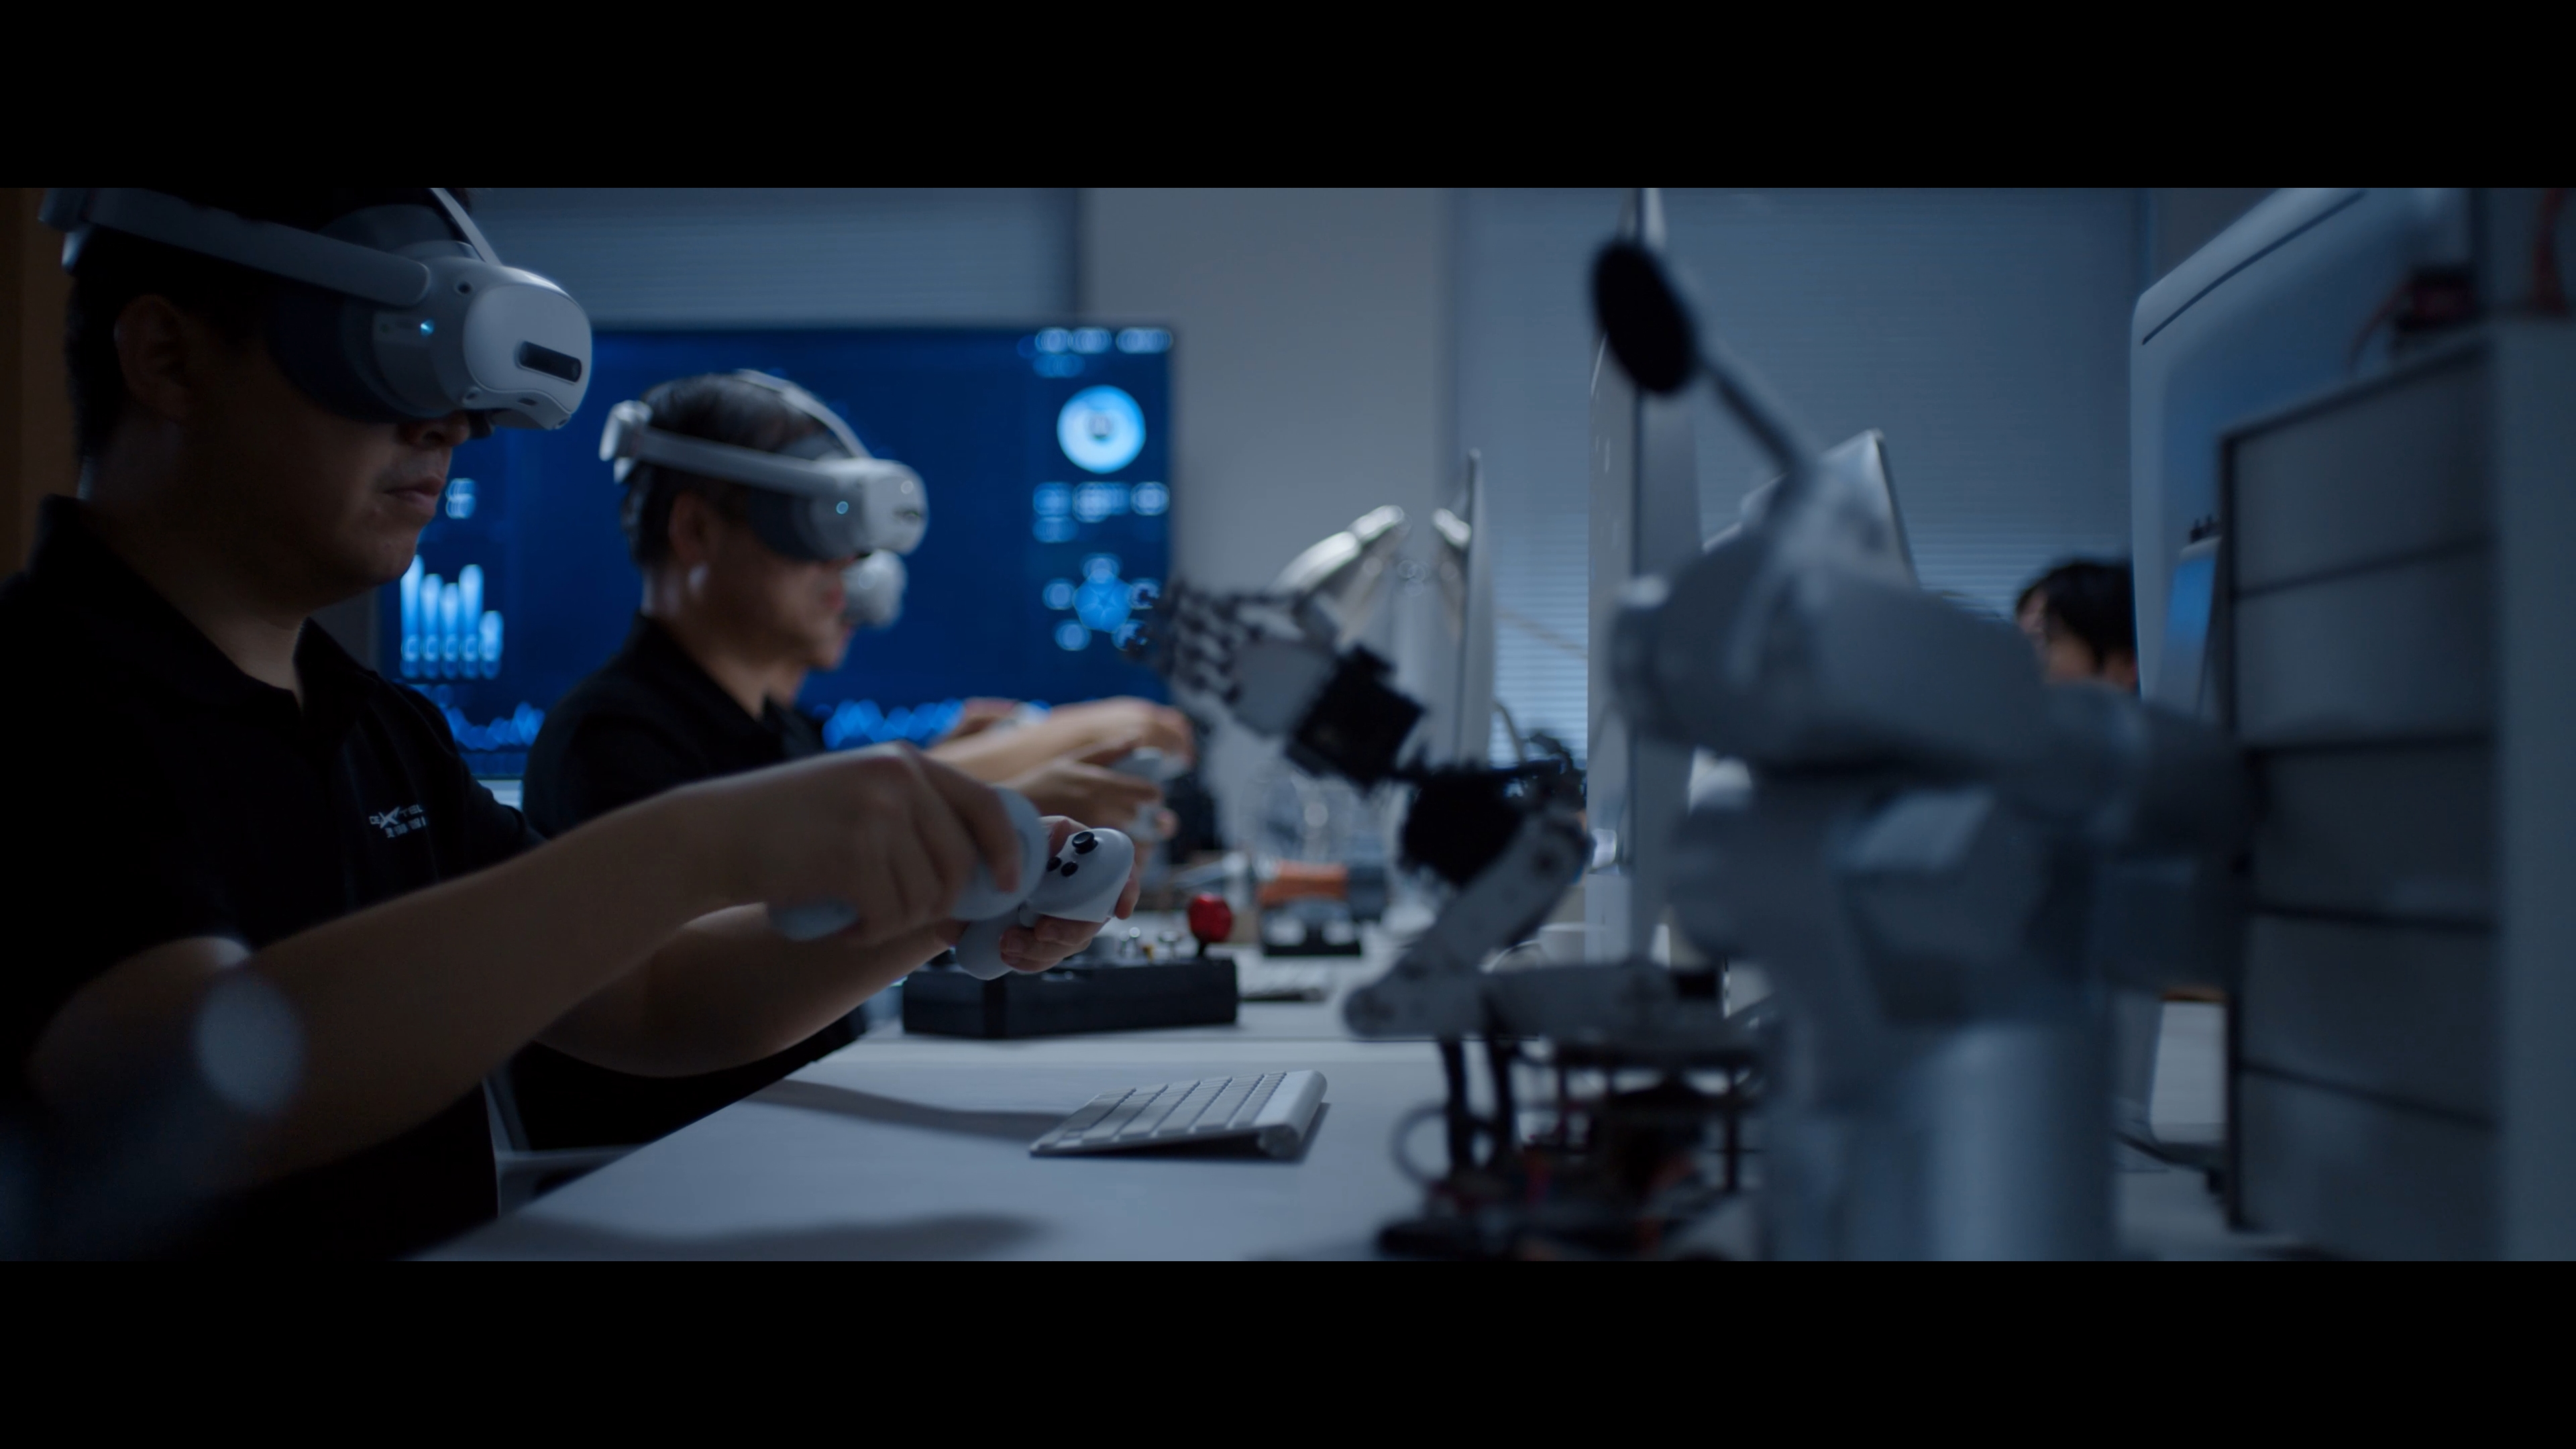
Research & Data Collection
High-throughput experimental operations, environmental data collection, sample processing
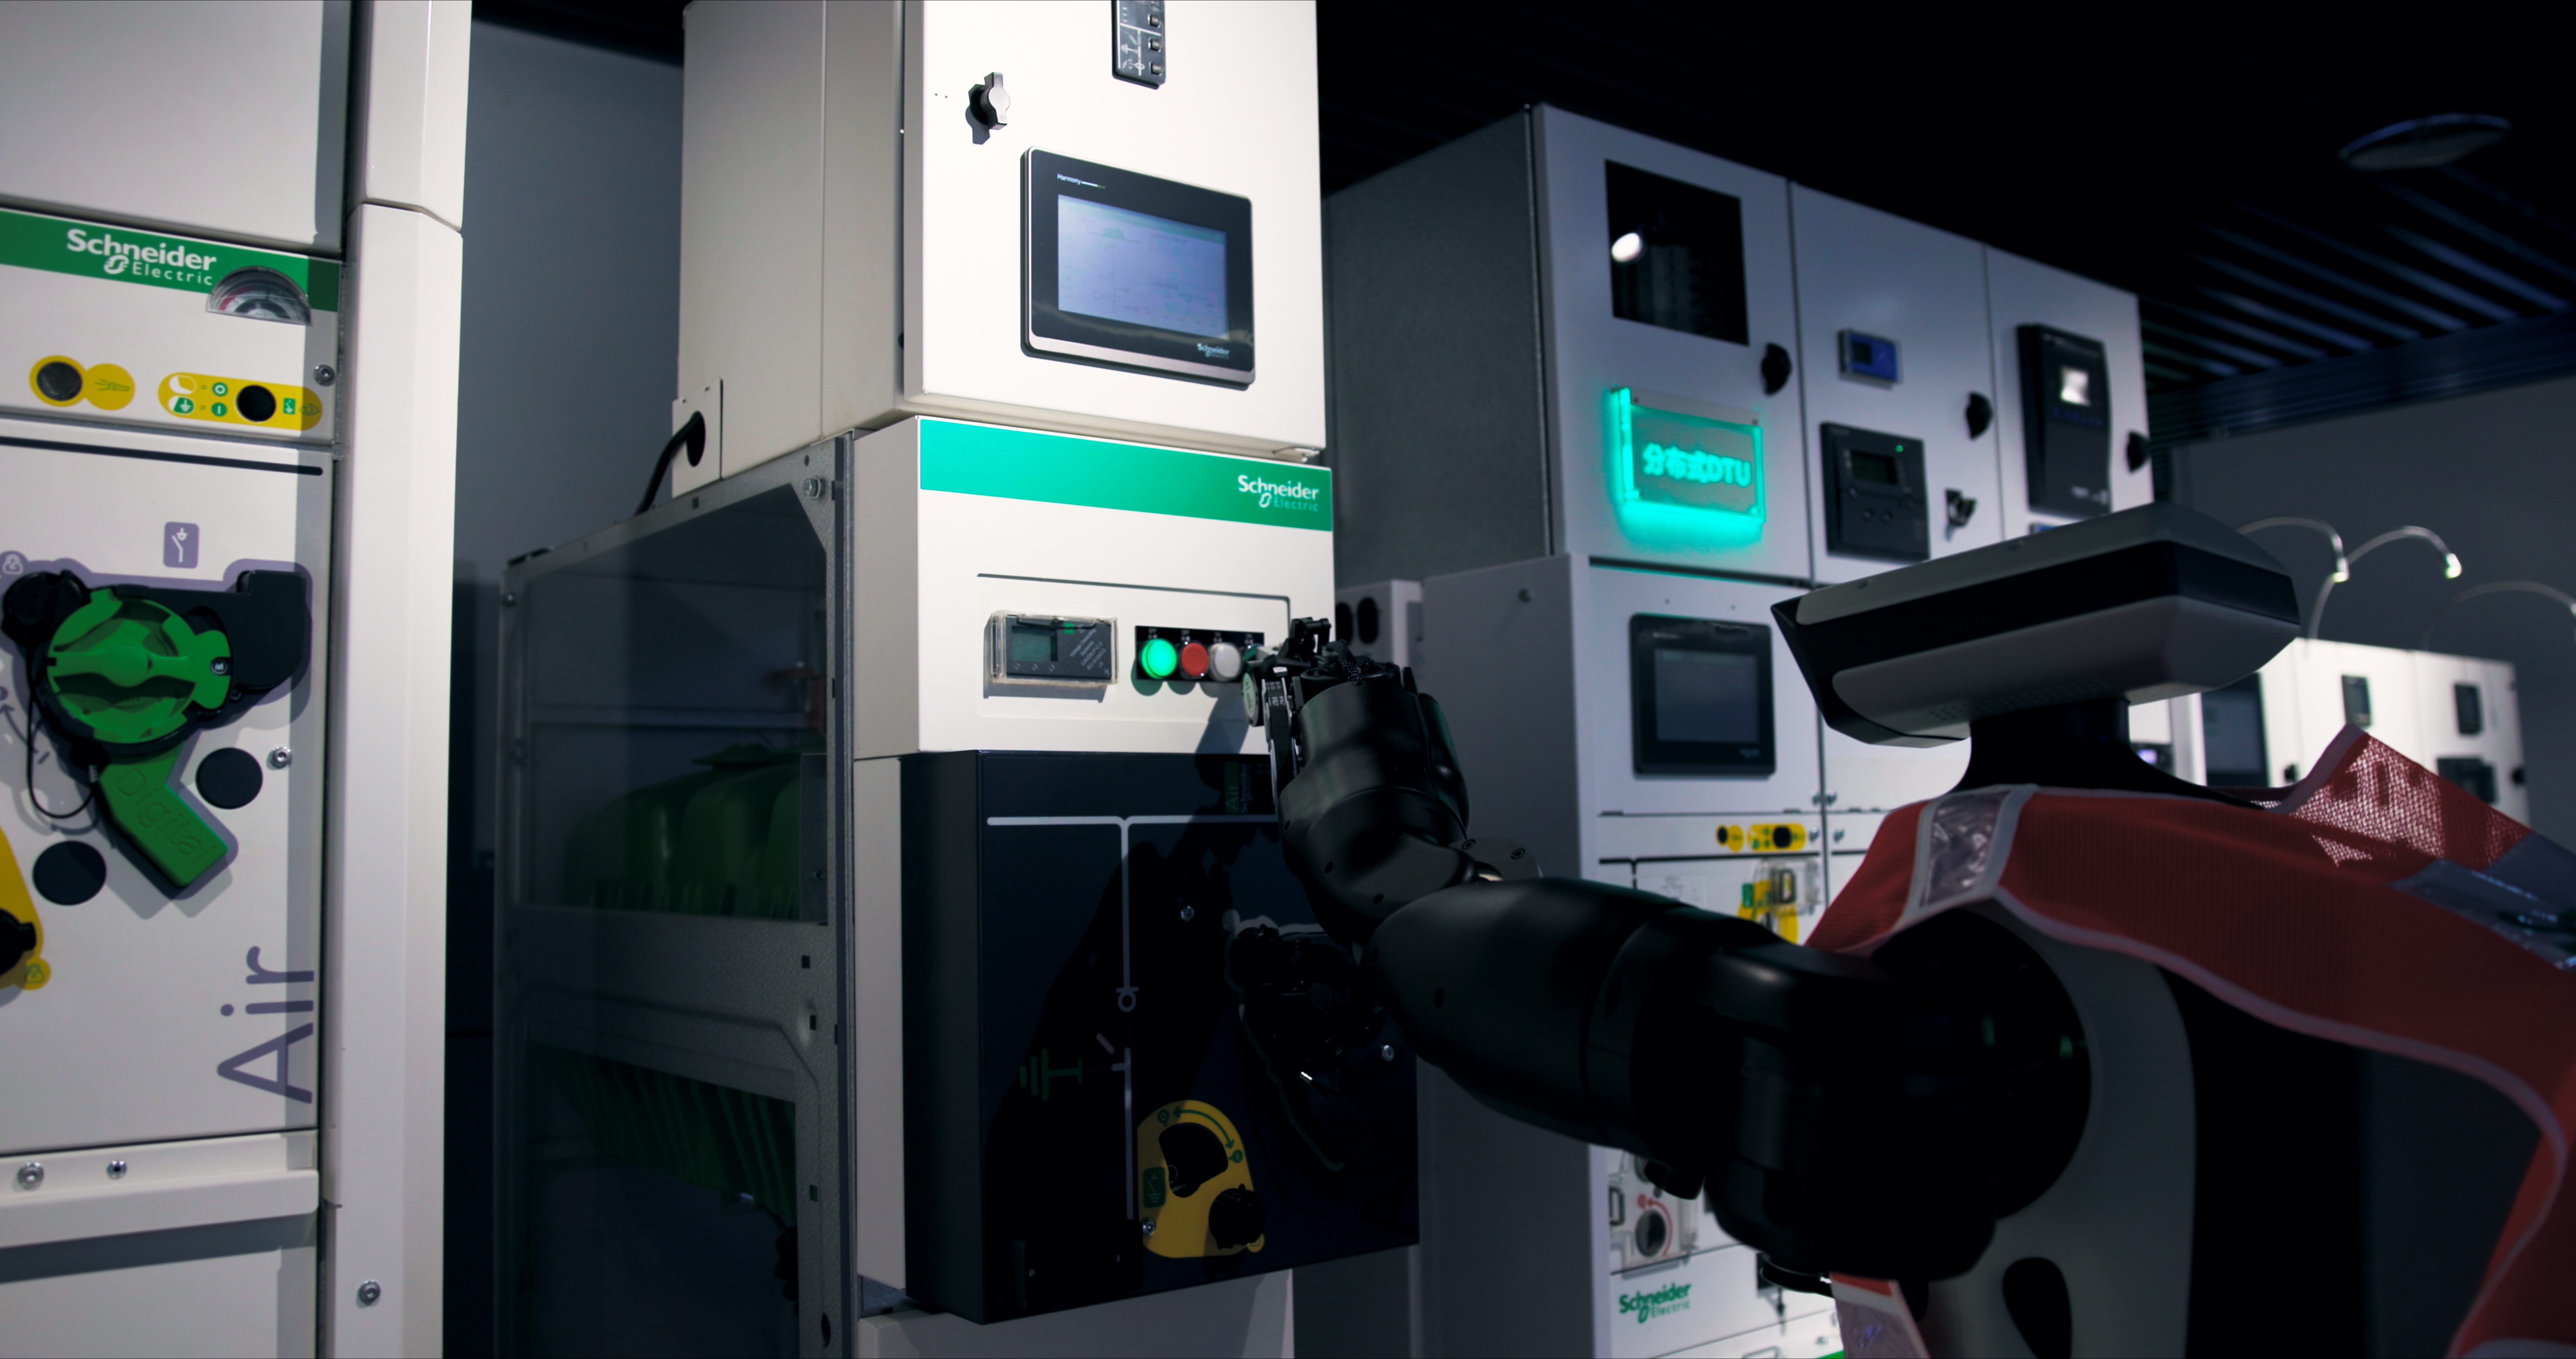
Special & High-risk Scenarios
Nuclear power inspection, chemical plant operations and other special environments cleared by on-site assessment
Deployment & Upgrade
Rapid Deployment
Targeted implementation support based on application requirements and on-site conditions
Operator Training
Training around control workflows, task execution and daily use to help teams complete onboarding quickly
Operation & Maintenance Support
Platform-based management and remote support to improve operational efficiency and problem response speed
Custom Extension
Feature extension and scenario adaptation for different industries and task requirements
Other Products
DexUMI Collection Device
Robot-free data collection device based on a vision–inertial fusion UMI architecture
Horus Video Transmission System
Self-developed multimodal video transmission system, stable delivery at a minimum of 5 Mbps public bandwidth
LingYu Data Platform
Data management platform covering collection, upload, review, annotation and training preparation
Nexus Edge-Cloud Architecture
Low-latency links connecting cloud AI with LingYu TA robots
Contact Us
Product inquiries, data services, partnerships and press all start here. Tell us what you need in the form.
Your details are used for this inquiry only.