DexUMI Collection Device
Robot-free data collection device based on a vision–inertial fusion UMI architecture, 300 g+ per unit, supporting on-site data collection and training preparation.
DexUMI is the robot-free data collection device in the LingYu TA robot ecosystem. Designed for TA robots, the data it collects can be used for TA model training and migrated to real-robot validation, reducing the cost of moving from data collection to physical deployment. The device tracks the left and right hands independently, recording posture changes and operation trajectories in real time; each unit weighs 300 g+ and supports offloading compute to a backpack or external computing unit, making it suitable for portable data collection and training preparation.
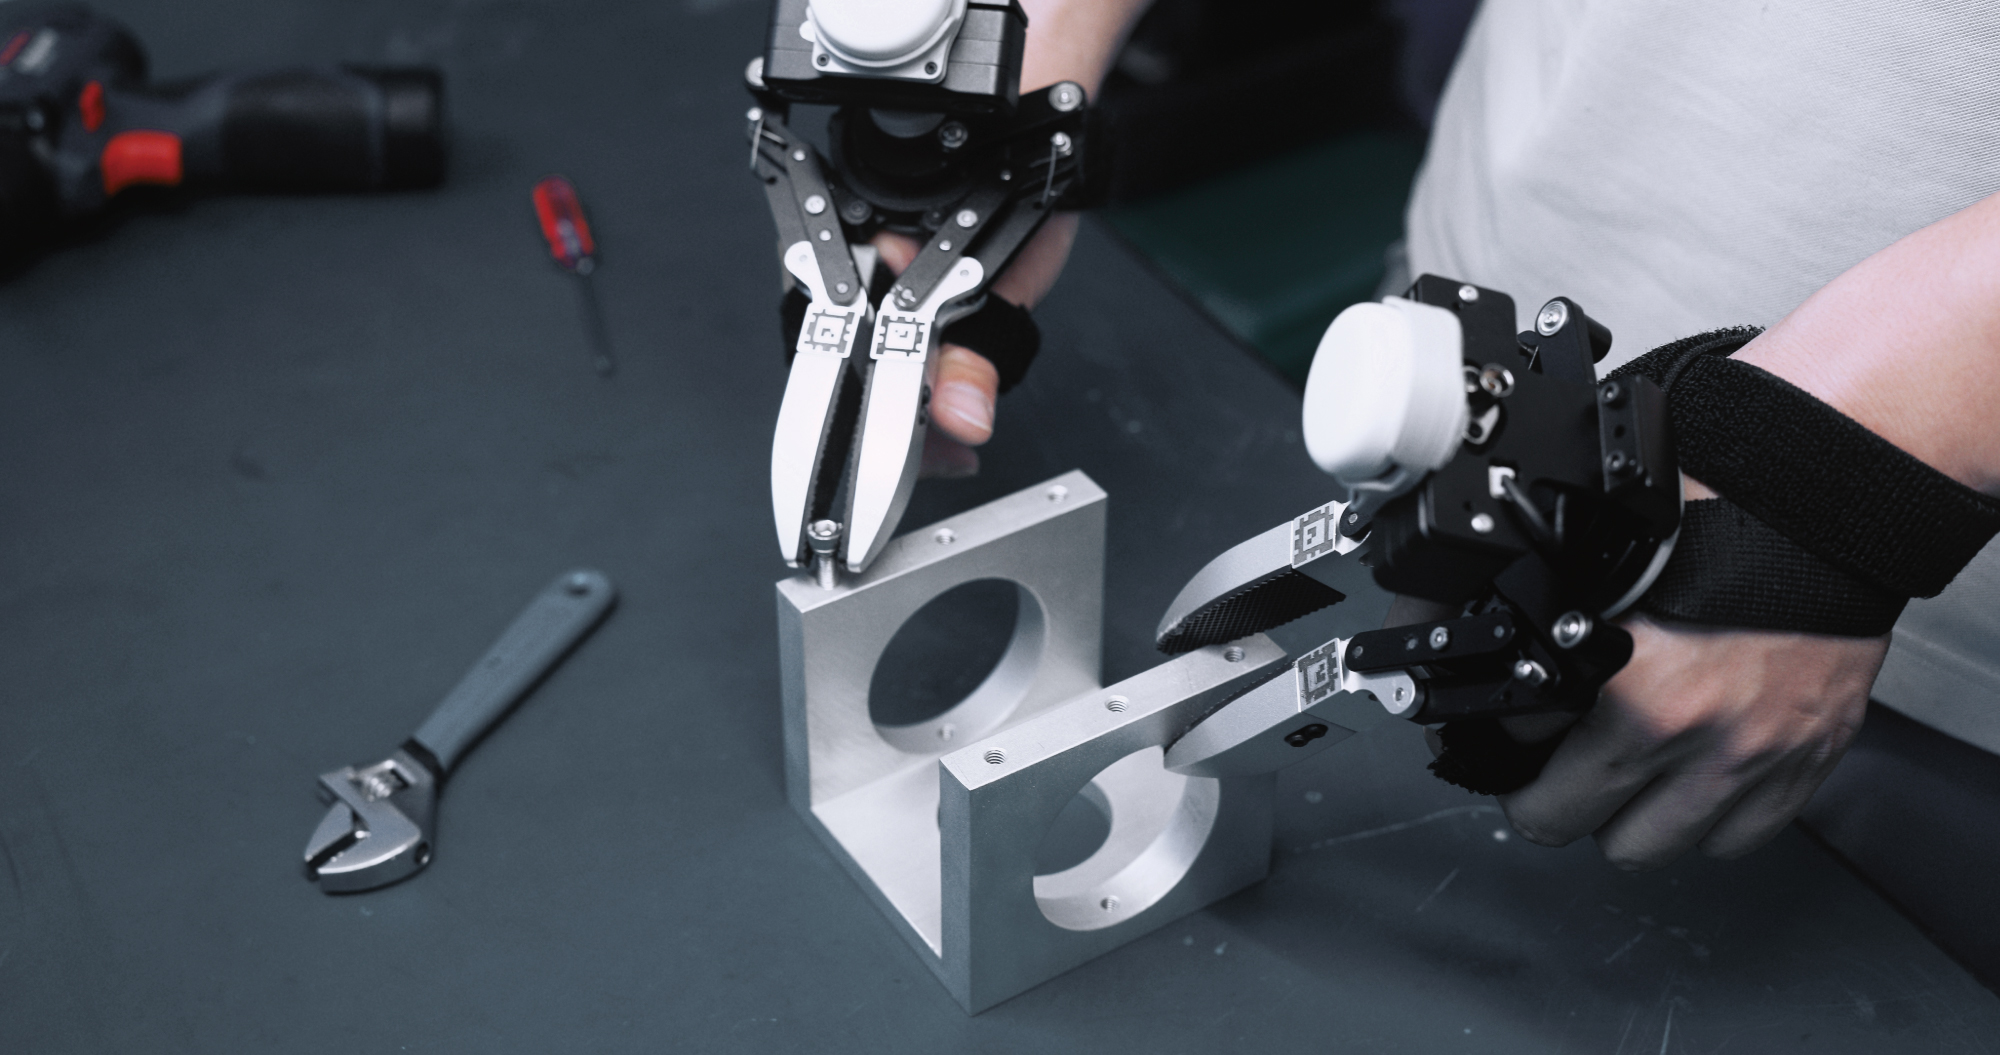
Core Advantages
TA Isomorphism
Designed for TA robots; collected data can be used for model training and real-robot validation.
Lightweight Design
300 g+ per unit, supporting up to 1 kg of applied force, suitable for portable data collection.
High-precision Tracking
Independent left- and right-hand tracking, recording posture changes and operation trajectories in real time.
Multimodal Perception
Captures RGB video, depth, IMU and audio data with hardware-level timestamp alignment.
Rapid Deployment
No mapping required; supports data collection and training preparation across a range of scenarios.
Technical Parameters
VR Headset
UMI Gripper
Compute Unit
Application Scenarios
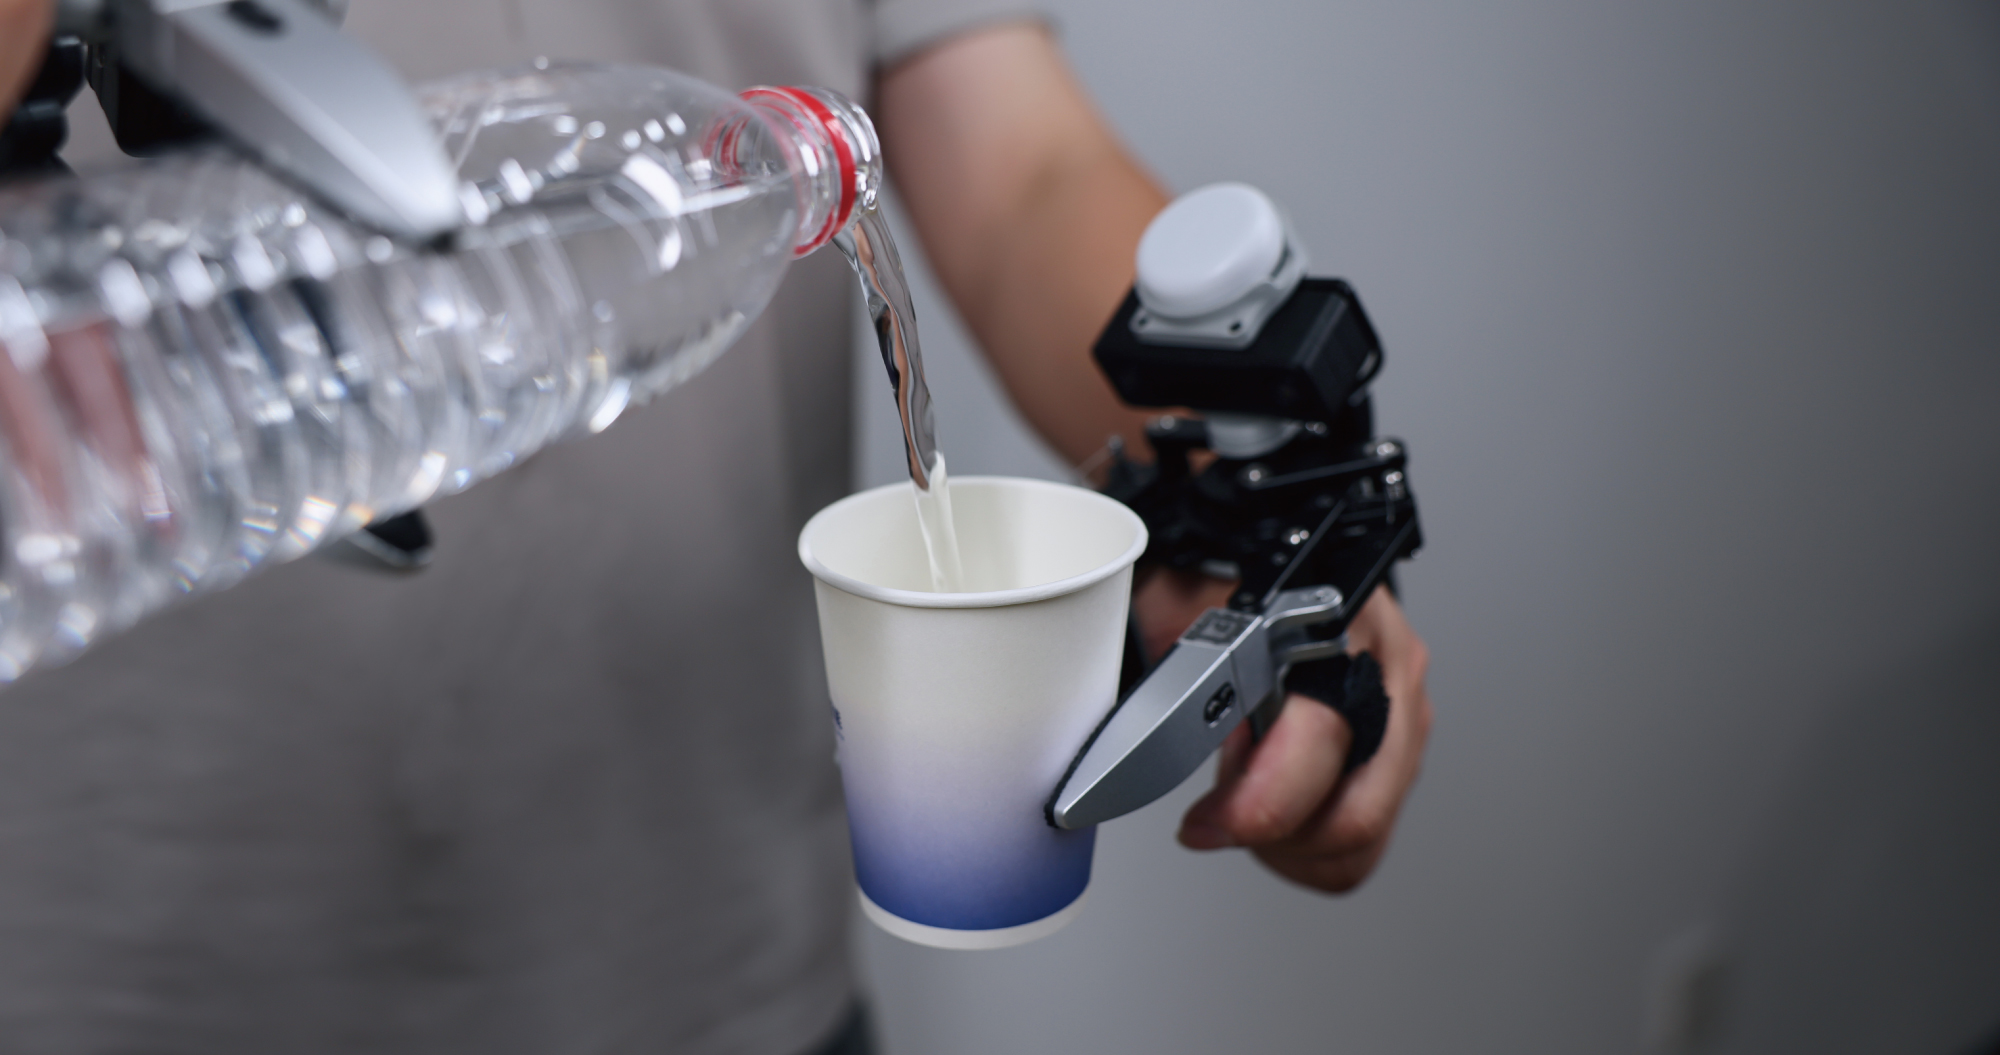
Human-Robot Alignment & Imitation Learning
Build robot training demonstration datasets.
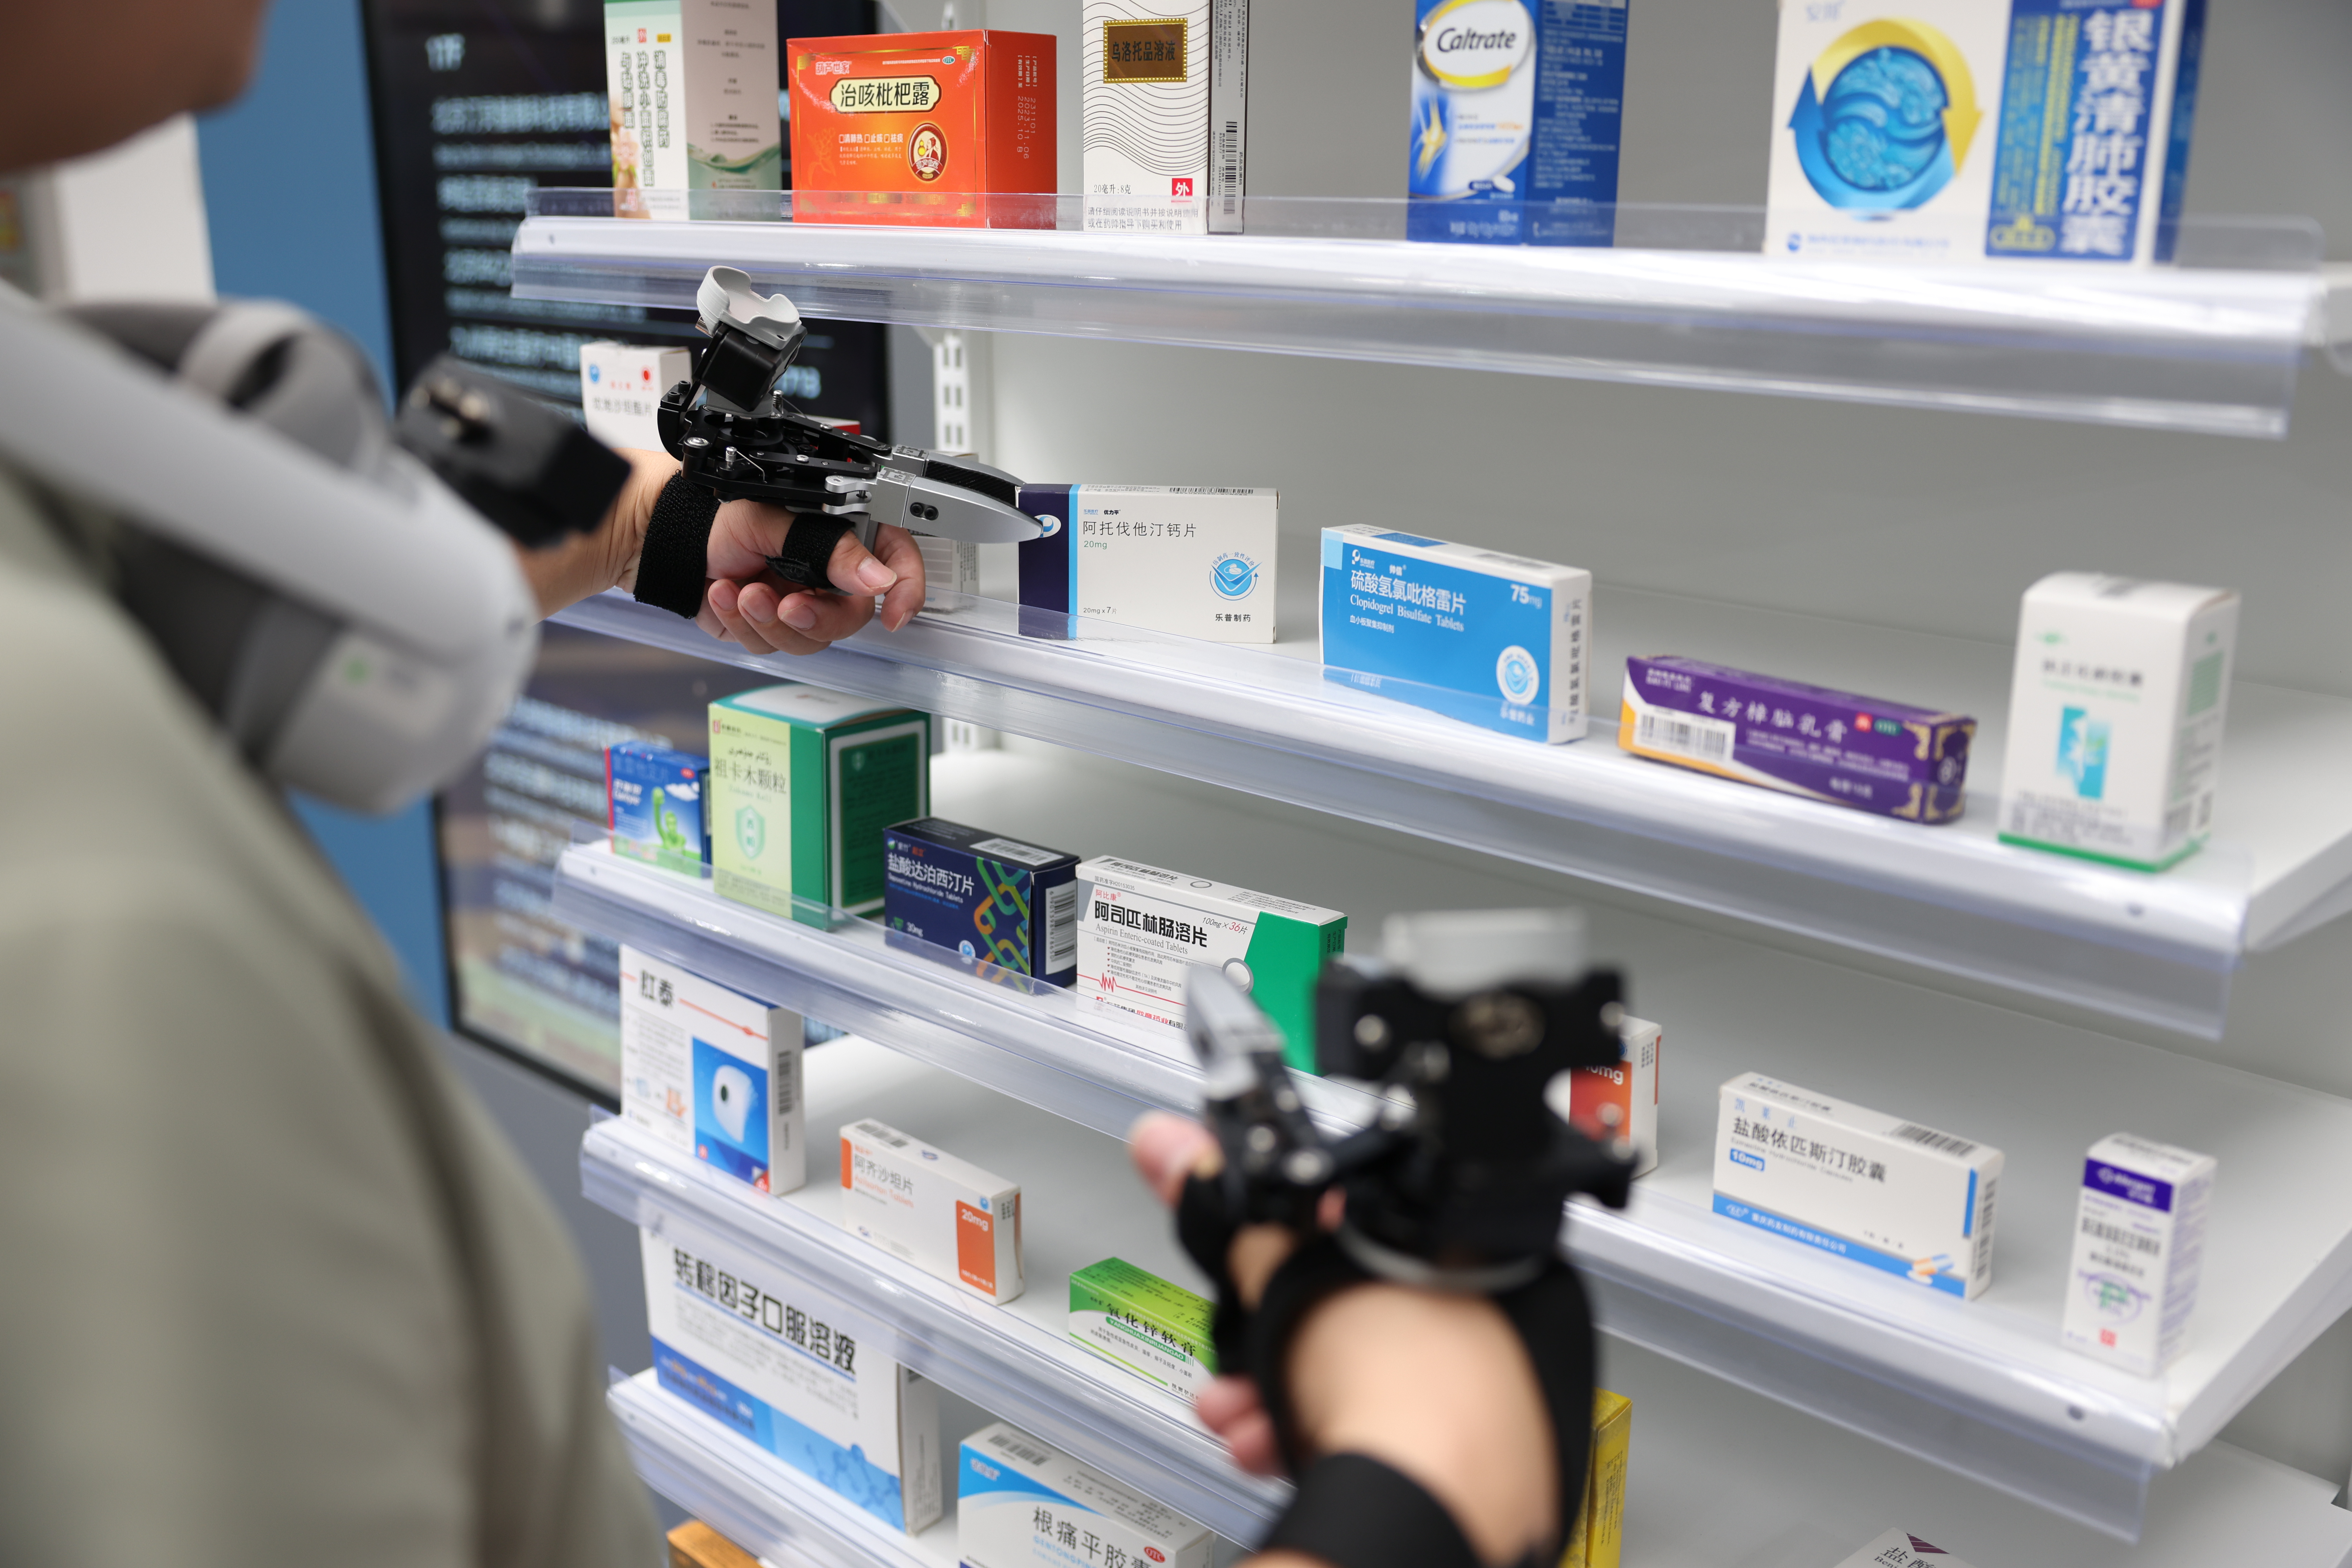
Fine Manipulation Learning
Supports tasks such as grasping, assembly and tool use.
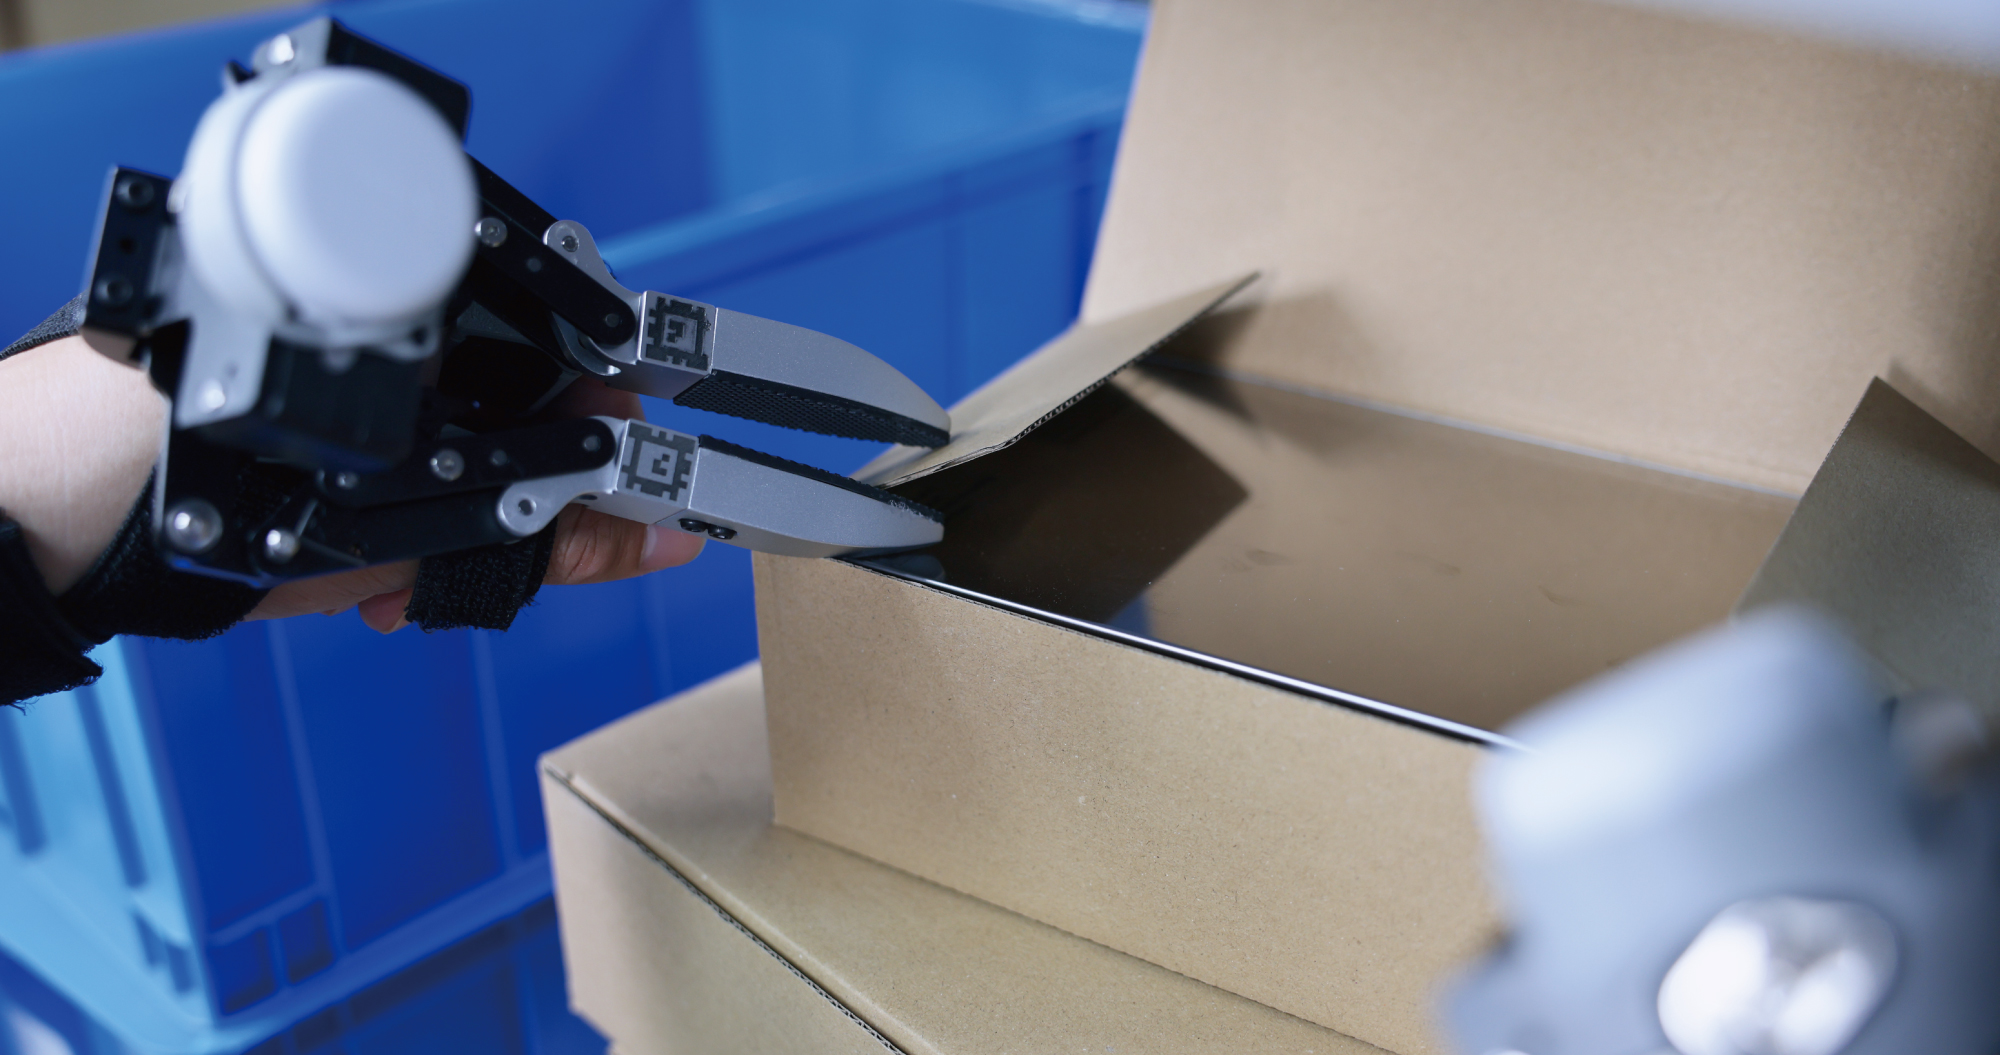
Long-sequence Task Modeling
Supports continuous tasks such as pouring, tidying and packing.
Other Products
LingYu TA2 Robot
High-performance dual-arm robot for multi-scenario remote operations
Horus Video Transmission System
Self-developed multimodal video transmission system, stable delivery at a minimum of 5 Mbps public bandwidth
LingYu Data Platform
Data management platform covering collection, upload, review, annotation and training preparation
Nexus Edge-Cloud Architecture
Low-latency links connecting cloud AI with LingYu TA robots
Contact Us
Product inquiries, data services, partnerships and press all start here. Tell us what you need in the form.
Your details are used for this inquiry only.